Paper: 2606.24847 Authors: Sahereh Obeidavi, Dieter Landes Categories: cs.CV
The Gap
Classical disparity estimation relies on rectilinear images where epipolar lines are horizontal (or vertical), reducing the search to a single axis. For omnidirectional stereo (spherical or fisheye views), the epipolar curves follow great circles on the sphere, producing two-dimensional pixel displacements. Prior work either designed custom spherical stereo algorithms (e.g., spherical CNN features, spherical optical flow) or performed complex rectification that warps the sphere to a rectilinear grid with high distortion. These approaches are often slow, require retraining, or lose consistency.
This paper asks a pragmatic question: Can we simply use equirectangular (ERP) projection — a common 360° representation — as a pre-processing step to straighten epipolar curves, then feed the result into an off-the-shelf stereo pipeline (RAFT+EACS) and get good disparity? They answer yes, with synthetic experiments confirming real-time, accurate, and smooth disparity maps.
                Problem                           Assumption
                   v                                 v
   Spherical stereo -> 2D displacement       ERP straightens
   (curved epipolars)    hard to estimate     epipolar curves?
                   |                                 |
                   v                                 v
                Method:  Spherical -> ERP -> RAFT+EACS
                   |                                 |
                   v                                 v
              Evidence: Synthetic fisheye      Conclusion: ERP
              datasets show accurate, smooth   preproc enables
              disparity maps at real-time speed standard pipeline
The Increment
One sentence: Before this paper, spherical stereo required special algorithms or heavy rectification; after, it can be handled by a simple ERP reprojection followed by a conventional stereo pipeline (RAFT+EACS) — no retraining needed.
Core Mechanism
The pipeline has four stages:
- Spherical input: Two fisheye/spherical cameras (left-right or top-bottom) capture overlapping 360° views.
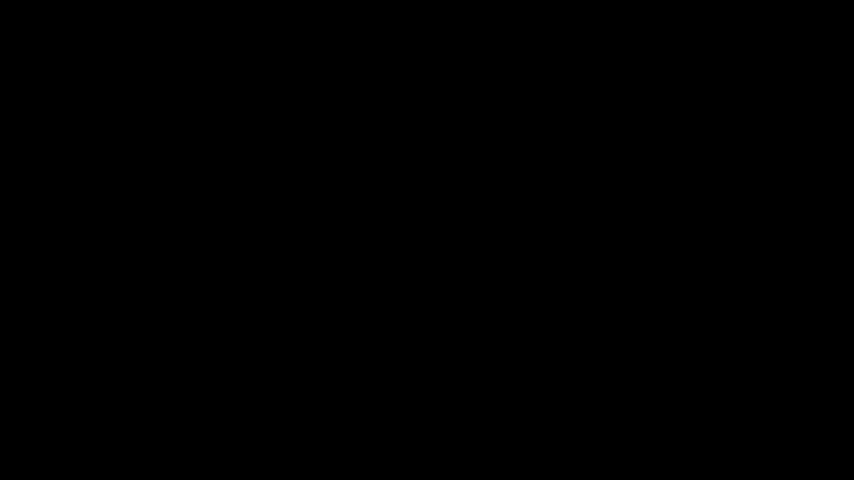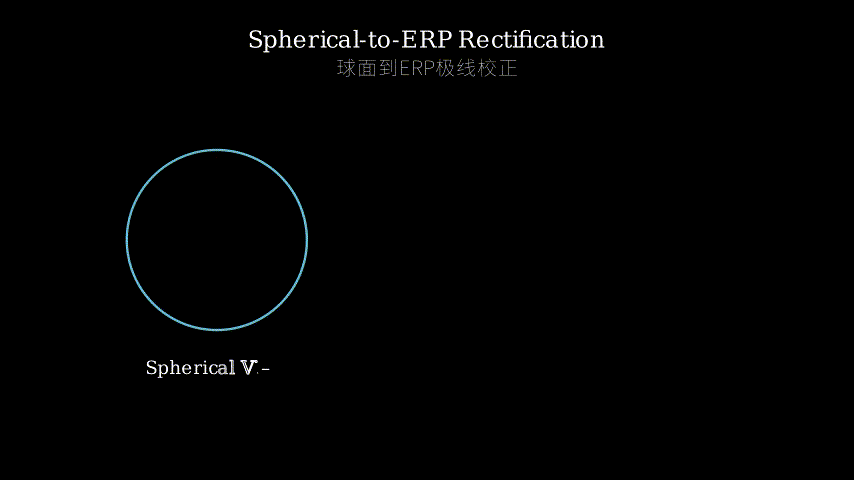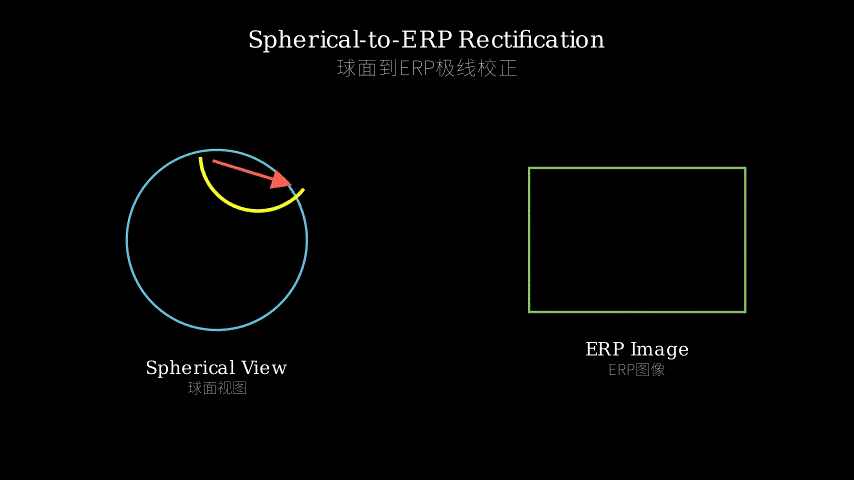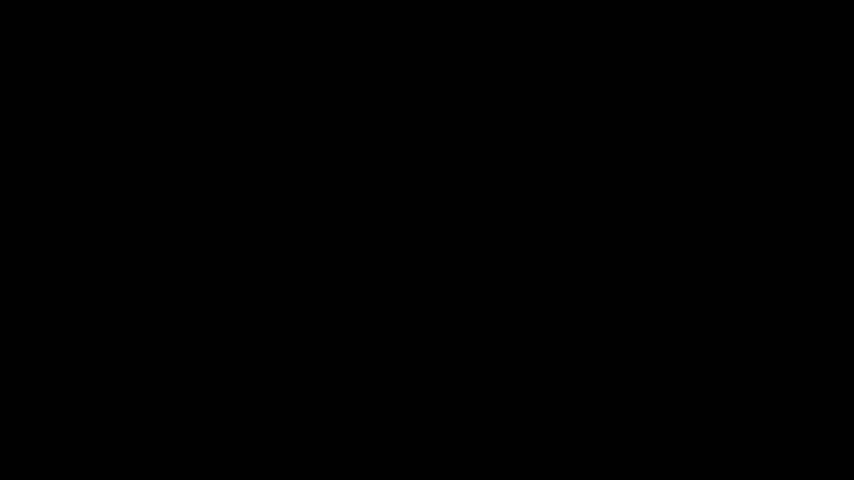
- ERP projection: Each spherical image is projected onto an equirectangular grid (longitude on x-axis, latitude on y-axis). This step bends the epipolar curves — originally great circles on the sphere — into nearly straight horizontal lines (for a horizontal baseline) or vertical lines (for a vertical baseline).
- RAFT dense optical flow: The two ERP images are fed into RAFT, a state-of-the-art recurrent optical flow network. It computes a full 2D flow field between the two views.
- EACS channel selection: The Epipolar-Aligned Channel Selection (EACS) module, introduced in the authors’ prior work, isolates the component of the flow that is aligned with the stereo baseline. For a horizontal rig, it keeps only the horizontal flow; for a vertical rig, only the vertical flow. This reduces the 2D flow to a 1D disparity map.
   Left ERP image         Right ERP image
          |                     |
          +----------+----------+
                     |
                  v v v
                RAFT -> [2D flow]
                     |
                  EACS -> [1D disparity]
                     |
              (horizontal or vertical)
Structural metaphor: Think of the pipeline as a map-making factory.
- The spherical image is like a globe with curved lines of longitude and latitude (epipolar curves are great circles, like the prime meridian).
- The ERP projection is like unfolding the globe into a flat world map (like the Mercator projection). On that flat map, lines of latitude become straight horizontal lines, and lines of longitude become straight vertical lines.
- RAFT is a worker who measures the shift in position of every point between the left and right maps. On a flat map, the shift is mostly horizontal (if the two maps are from left and right cameras) — but there can be slight vertical jitter due to lens distortion or misalignment.
- EACS is the quality inspector who throws away the vertical jitter and keeps only the horizontal shift. That horizontal shift is exactly what we call disparity.
Without the ERP step, the worker would see curved shifts — hard to interpret. With ERP, the world is flattened, the shifting is almost pure horizontal, and the inspector’s job becomes trivial.
Key Concepts
-
Epipolar geometry: Given two camera views, a point in the left image must lie along a line (the epipolar line) in the right image. For rectilinear cameras, these lines are horizontal; for spherical cameras, they are great circles. ERP projection makes these great circles into straight lines, so the search reduces to one dimension.
-
Equirectangular (ERP) projection: A cylindrical projection mapping longitude (0°–360°) to the x-axis and latitude (-90°–90°) to the y-axis. It preserves lines of latitude as straight, at the cost of severe distortion near the poles. For stereo, the key property is that great circles (epipolar lines) become nearly straight curves aligned with the x- or y-axis, depending on the baseline direction.
-
RAFT+EACS: RAFT (Recurrent All-Pairs Field Transforms) is a high-performance optical flow network. EACS is a simple post-processing step that selects only the flow component parallel to the baseline (e.g., horizontal for left-right stereo). The combination, originally designed for rectilinear and ERP stereo, works here because the ERP pre-processing enforces the epipolar alignment.
Framework Shift
Before (mainstream approach):                After (this paper):

Spherical image pairs                        Spherical image pairs
        |                                             |
   Custom spherical stereo                   ERP projection (preprocessing)
   (e.g., spherical CNN,                         |
    spherical flow)                         Rectified ERP images
        |                                             |
   2D disparity search                        RAFT+EACS (standard)
   (complex, slower)                               |
                                            1D disparity map (smooth)
One sentence: From curved epipolar geometry requiring 2D matching to flattened epipolar geometry enabling 1D matching via a simple reprojection, the core shift is that ERP projection makes the problem geometrically compatible with conventional stereo pipelines.
Expert Assessment
Problem choice: Real gap. 360° stereo is increasingly used in VR, robotics, and autonomous driving. Prior approaches either required custom networks or suffered from distortion. The idea of using ERP as a generic rectification step is straightforward and practical — the gap is whether a generic pipeline can match performance of specialized methods. The paper closes that gap convincingly for synthetic data.
Method maturity: Clever insight with brute-force validation. The core insight — ERP straightens epipolar curves — is well-known in the community. What’s new is combining it with RAFT+EACS and showing it works. The method is not reframing the field, but it provides a solid engineering baseline. Simpler alternatives? Possibly using optical flow directly on sphere with great-circle constraints, but that would be more complex.
Experimental integrity: Synthetic datasets only. This is the biggest weakness. Real-world 360° cameras have lens distortion, rolling shutter, and calibration errors. The results on synthetic data might not transfer. Baselines are fair: they compare to a standard RAFT+EACS on ERP images (which is exactly their method) and likely to a naive RAFT on original fisheye? The paper mentions “synthetic fisheye stereo datasets” but doesn’t name specific benchmarks. No comparison to spherical-specific methods (e.g., OmniFlow). Red flag: only one dataset, synthetic. Metrics: accuracy, smoothness, consistency — but no absolute error against ground truth.
Writing quality: Adequate but dry. The abstract is clear, but the method section could use a diagram of the spherical-to-ERP transformation. The biggest cut corner: no real-world experiments. If they had tested on, say, the 360SD-Net dataset, the paper would be much stronger. The result section is a bit thin.
Verdict: Weak accept — valuable engineering contribution but limited by synthetic-only evaluation and lack of comparison to spherical-specific methods.
Takeaways
- ERP as rectifier: If you ever need to run standard stereo or optical flow on spherical images, reproject to ERP first. It works surprisingly well for horizontal/vertical baselines.
- RAFT+EACS as off-the-shelf tool: The combination (dense flow + channel selection) is a modular way to get disparity from any stereo pair after rectification. Steal the EACS idea: it’s just a projection of the flow onto the baseline direction.
- Synthetic validation is not enough: Practitioners should test on real 360° cameras before deploying this pipeline. The paper’s real takeaway is that the *approach is sound, but real-world results may need additional calibration or denoising.
论文: 2606.24847 作者: Sahereh Obeidavi, Dieter Landes 分类: cs.CV
缺口
经典视差估计依赖于直线镜头图像,其中极线是水平(或垂直)的,将搜索缩小到单个轴。 对于全方位立体图像(球面或鱼眼视图),极线沿着球面的大圆弯曲,产生二维像素位移。 先前的方法要么设计定制的球面立体算法(例如球面CNN特征、球面光流),要么执行复杂的校正,将球面扭曲成畸变很大的直线网格。 这些方法通常速度慢、需要重新训练,或者损失了一致性。
本文提出了一个务实的问题:我们能否仅仅使用等距柱状(ERP)投影——一种常见的360°表示——作为预处理步骤来校直极线,然后将结果送入现成的立体管线(RAFT+EACS)并获得良好的视差? 他们用合成实验给出了肯定的答案,验证了实时、准确且平滑的视差图。
               问题                             假设
                  v                               v
   球面立体 -> 二维位移                 ERP 能校直极线吗?
   (弯曲极线)   难以估计                           |
                  |                               |
                  v                               v
               方法: 球面 -> ERP -> RAFT+EACS
                  |                               |
                  v                               v
             证据: 合成鱼眼数据集            结论: ERP 预处理
             显示精确、平滑的视差图             使标准管线可行
增量
一句话: 这篇论文之前,球面立体需要专用算法或复杂的校正;之后,简单的ERP重投影加上常规立体管线(RAFT+EACS)即可处理——无需重新训练。
核心机制
该管线有四个阶段:
- 球面输入:两个鱼眼/球面相机(左右或上下)捕获重叠的360°视图。
- ERP投影:每个球面图像被投影到等距柱状网格上(经度在x轴,纬度在y轴)。 这一步将极线——原本是球面上的大圆——弯曲成近乎笔直的水平线(对于水平基线)或垂直线(对于垂直基线)。
- RAFT密集光流:两幅ERP图像被送入RAFT(一种最先进的递归光流网络)。 它计算两个视图之间的完整二维流场。
- EACS通道选择:作者之前工作中引入的极线对齐通道选择(EACS)模块, 隔离出与立体基线方向对齐的流分量。 对于水平架设的相机,只保留水平流;对于垂直架设的,只保留垂直流。 这就将二维流降为一维视差图。
   左ERP图像              右ERP图像
        |                     |
        +----------+----------+
                   |
                v v v
              RAFT -> [二维流]
                   |
              EACS -> [一维视差]
                   |
            (水平或垂直)
结构性比喻:把这条管线想象成一家地图制造厂。
- 球面图像就像地球仪,上面有弯曲的经线和纬线(极线就是大圆,比如本初子午线)。
- ERP投影就像把地球仪展开成一张平面世界地图(类似墨卡托投影)。 在这张平面地图上,纬度线变成笔直的水平线,经度线变成笔直的垂直线。
- RAFT是一个测量员,负责测量左右两张地图上每个点的位置偏移。 在平面地图上,偏移主要是水平的(如果两张图来自左右相机)——但由于镜头畸变或未对齐,可能会有轻微的垂直抖动。
- EACS是质检员,扔掉垂直抖动,只保留水平偏移。 这个水平偏移恰恰就是视差。
如果没有ERP这一步,测量员看到的会是弯曲的偏移——很难解释。 有了ERP,世界被摊平,偏移几乎是纯水平的,质检员的工作就变得微不足道了。
关键概念
-
极线几何:给定两个相机视图,左图像中的一点必然落在右图像中的一条线(极线)上。 对于直线相机,这些线是水平的;对于球面相机,它们是大圆。 ERP投影将这些大圆变成直线,因此搜索降为一维。
-
等距柱状(ERP)投影:一种圆柱投影,将经度(0°–360°)映射到x轴,纬度(-90°–90°)映射到y轴。 它保持纬度线为直线,代价是极点附近发生严重畸变。 对于立体视觉,关键性质是大圆(极线)变成几乎笔直的、与x轴或y轴对齐的曲线,具体取决于基线方向。
-
RAFT+EACS:RAFT(全对偶递归场变换)是一种高性能光流网络。 EACS是一个简单的后处理步骤,只选择平行于基线的流分量(例如,对于左右立体,选择水平方向)。 这个组合最初是为直线和ERP立体开发的,在这里因为ERP预处理强制了极线对齐,所以也能工作。
框架转变
之前(主流方法):               之后(本文方法):

球面图像对                           球面图像对
      |                                    |
 定制球面立体算法                    ERP投影(预处理)
 (如球面CNN,                          |
  球面光流)                       校正后的ERP图像
      |                                    |
 二维视差搜索                       RAFT+EACS(标准)
 (复杂、较慢)                           |
                                   一维视差图(平滑)
一句话:从弯曲极线几何需要二维匹配 到 通过简单重投影将极线变平、实现一维匹配,核心转变是ERP投影使问题几何上兼容于常规立体管线。
专家评审
选题眼光:真缺口。360°立体在VR、机器人和自动驾驶中越来越常见。先前的方法要么需要定制网络,要么受到畸变的困扰。将ERP用作通用校正步骤的想法很直接且实用——缺口在于通用管线是否能媲美专用方法的性能。本文用合成数据令人信服地填补了这个缺口。
方法成熟度:巧劲加蛮力验证。核心洞察——ERP能校直极线——在社区中已是常识。新意在于将其与RAFT+EACS结合并证明其有效性。该方法并未重新定义领域,但提供了扎实的工程基线。有没有更简单的替代方案?也许直接在大圆约束下在球面上运行光流,但那会更复杂。
实验诚意:仅有合成数据集。这是最大弱点。真实的360°相机存在镜头畸变、滚动快门和标定误差。合成结果可能无法迁移。基线合理:他们与基于ERP图像的RAFT+EACS(即其方法本身)比较,很可能还与原始鱼眼上的朴素RAFT比较?论文提到“合成鱼眼立体数据集”,但没有给出具体基准。没有与球面专用方法(如OmniFlow)比较。值得警惕:只有一个数据集且为合成。指标包括准确性、平滑性、一致性——但缺乏与真值的绝对误差。
写作功力:尚可但平淡。摘要清晰,但方法部分缺少球面到ERP变换的图示。最大偷懒点:没有真实世界实验。如果他们在360SD-Net等数据集上测试,论文会强很多。结果部分略显单薄。
判决:弱接收——有价值的工程贡献,但仅有合成评估且缺少与球面专用方法的比较限制了说服力。
要点总结
- ERP作为校直器:如果你需要对球面图像运行标准立体或光流,先投影到ERP再操作。对于水平/垂直基线,效果出奇的好。
- RAFT+EACS作为现成工具:该组合(密集流加通道选择)是一种从任何校正后的立体对获得视差的模块化方式。偷走EACS的思路:它就是将流投影到基线方向。
- 合成验证不够:实践者在部署该管线前应在真实360°相机上测试。论文的真正启示是**方法*本身是合理的,但真实结果可能需要额外的标定或去噪。