Paper: 2605.12494 Authors: Jiahe Li, Jiawei Zhang, Xiao Bai, Jin Zheng, Xiaohan Yu, Lin Gu, Gim Hee Lee Categories: cs.CV
The Gap
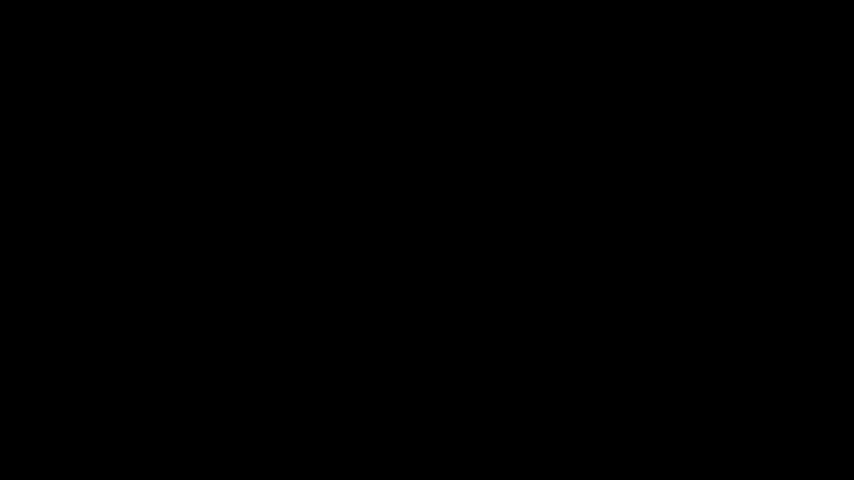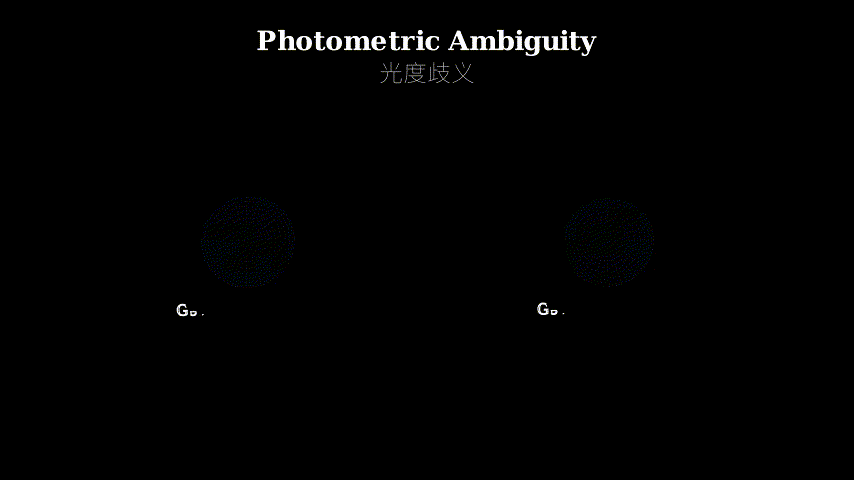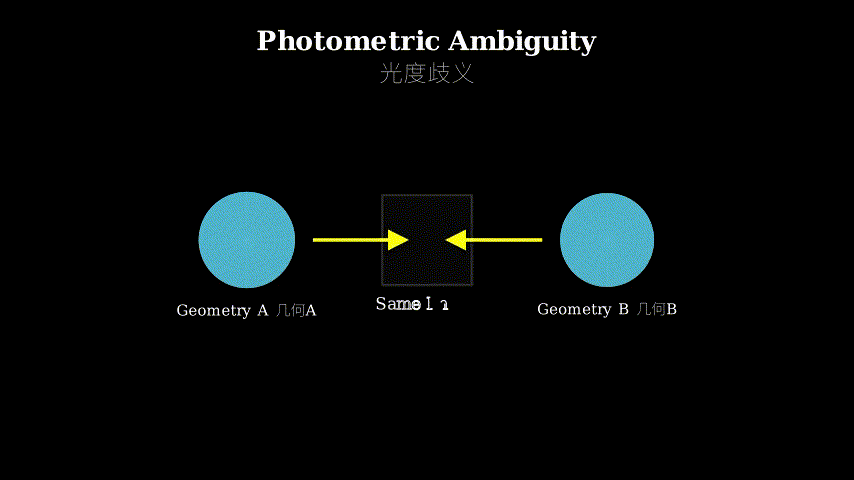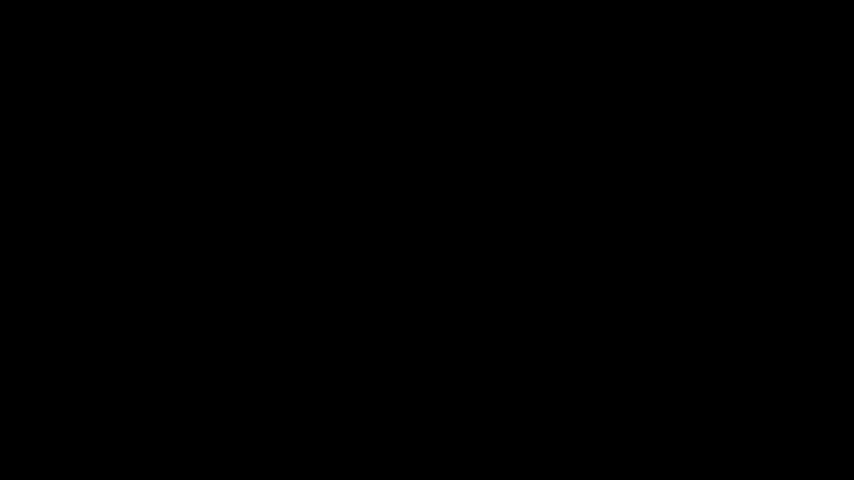
Differentiable rendering methods like NeRF and Gaussian Splatting have pushed 3D reconstruction forward, but they hit a fundamental wall: photometric ambiguity. The same image can result from infinitely many geometry-appearance combinations—a flat white surface under bright light looks identical to a bumpy gray surface under dim light. Prior work (NeuS, VolSDF, 2DGS) tries to constrain this with geometric priors or regularization, but these are external band-aids. They don’t address the fact that the representation itself is ambiguous at the primitive level.
Gaussian Splatting is particularly vulnerable. Each Gaussian primitive has independent opacity and color, creating two built-in ambiguities: (1) opacity-geometry coupling—you can’t tell if a surface is truly there or just highly transparent, and (2) color-lighting entanglement—is that brightness from surface albedo or illumination? Existing methods either ignore this or apply global constraints that don’t respect per-primitive ambiguity.
Photometric Ambiguity Problem
       |
       v
   [Image I = Geometry * Appearance]
       |
       +---> Infinite solutions exist
       |
       v
Prior approaches:           This paper:
Global regularization  -->  Primitive-level disambiguation
External constraints   -->  Self-indication mechanism
       |                           |
       v                           v
Still ambiguous            Definite surface
The Increment
One sentence: Before AmbiSuR, Gaussian Splatting reconstructions were plagued by phantom geometry from unresolved primitive-level ambiguities; after, the representation itself signals where it’s uncertain and self-corrects.
Core Mechanism
AmbiSuR operates in two stages. First, photometric disambiguation constrains the ill-posed geometry problem. For each Gaussian primitive, it enforces that opacity and geometry must align—if a primitive claims to be opaque, its center must lie on the actual surface, not floating in space. This breaks the opacity-geometry ambiguity by tying opacity values to geometric consistency through a depth-normal alignment loss.
Second, an ambiguity indication module exploits a hidden property of Gaussian Splatting: primitives that are underconstrained (ambiguous) naturally exhibit higher variance in their gradient updates during training. The module tracks this variance as a confidence signal. Low-confidence primitives get flagged, then corrected through targeted geometric refinement—adjusting their positions and scales to match nearby high-confidence geometry.
Input: Multi-view images
       |
       v
   [Gaussian Splatting Representation]
       |
       +---> Stage 1: Photometric Disambiguation
       |         |
       |         +---> Opacity-Depth Alignment
       |         +---> Normal Consistency Check
       |         |
       |         v
       |     Constrained Geometry
       |
       +---> Stage 2: Ambiguity Indication
             |
             +---> Track gradient variance per primitive
             +---> Flag low-confidence Gaussians
             +---> Refine flagged primitives
             |
             v
         Corrected Surface
Think of it like a sculptor working with clay. The clay (Gaussian primitives) can be shaped into any form, but some areas are mushy and unstable (ambiguous). Stage 1 is like adding an armature—a skeleton that forces the clay to respect the underlying structure. You can’t just pile clay anywhere; it must follow the armature’s shape. Stage 2 is the sculptor’s hand checking firmness: press each spot, and if it’s still soft (high gradient variance), reshape it to match the firm areas nearby. The clay itself tells you where it needs more work.
Key Concepts
-
Photometric Ambiguity: Imagine you’re looking at a photograph of a sphere. Is it a white sphere under dim light, or a gray sphere under bright light? Both produce the same image. In 3D reconstruction, this means the same set of photos can be explained by infinitely many combinations of shape (geometry) and color (appearance). The math doesn’t have enough information to pick one answer. Traditional methods add extra assumptions (smoothness, known lighting), but these are guesses. AmbiSuR instead looks at the representation’s internal structure to find where ambiguity hides and resolves it there.
-
Primitive-Level Ambiguity: Gaussian Splatting represents scenes as thousands of 3D Gaussian blobs. Each blob has its own opacity (how see-through it is) and color. The problem: you can make a surface look the same by using many transparent blobs stacked up, or fewer opaque blobs. Similarly, a bright blob far away can look like a dim blob up close. These aren’t just theoretical issues—during training, the optimizer gets stuck because multiple blob configurations produce identical images. AmbiSuR identifies these stuck configurations by watching how each blob’s parameters jitter during training.
-
Self-Indication: Here’s the clever bit. When a Gaussian primitive is ambiguous (multiple valid configurations), its gradients during training are inconsistent—one batch update pushes it left, the next pushes it right. High variance in gradient direction is a symptom of ambiguity. AmbiSuR doesn’t need external labels; it reads this variance as a confidence score. Low confidence = ambiguous = needs correction. It’s like a metal detector that beeps louder over uncertain areas, except the signal comes from the optimization process itself.
Framework Shift
Before (2DGS, SuGaR):                After (AmbiSuR):

Multi-view Images                    Multi-view Images
       |                                    |
       v                                    v
Gaussian Splatting                   Gaussian Splatting
       |                                    |
       +---> Global regularization          +---> Per-primitive disambiguation
       |     (smooth surfaces)               |     (opacity-depth alignment)
       |                                     |
       v                                     +---> Gradient variance tracking
Ambiguous geometry                          |     (self-indication)
(phantom surfaces,                          |
 floating blobs)                            v
                                      Definite surface
                                      (corrected primitives)
From global smoothness priors to primitive-level self-diagnosis, the core shift is treating ambiguity as a per-primitive property that the representation can signal and correct internally.
Expert Assessment
Problem choice: Real and well-motivated. Photometric ambiguity isn’t a niche issue—it’s the reason NeRF-based methods struggle with textureless regions and specular surfaces. Focusing on Gaussian Splatting’s built-in ambiguities is smart; the representation’s popularity makes this immediately relevant. The framing as “intrinsic solution” (fixing the representation itself) versus “extrinsic constraints” (adding regularization) is a genuine conceptual advance.
Method maturity: The photometric disambiguation is straightforward—depth-normal alignment is a known geometric consistency check, applied here at the primitive level. The novelty is in the ambiguity indication module. Using gradient variance as a confidence signal is clever, but the paper doesn’t deeply justify why variance specifically captures ambiguity versus other training instabilities (noisy data, learning rate issues). The refinement step (correcting low-confidence primitives) feels somewhat ad-hoc—it’s essentially spatial smoothing guided by confidence. A more principled approach might model ambiguity probabilistically.
Experimental integrity: Strong baselines (2DGS, SuGaR, GOF) and diverse datasets (DTU, Tanks and Temples, challenging real-world scans). The ablation studies isolate each component’s contribution. However, the paper doesn’t show failure cases or discuss when the method breaks. What happens in extremely low-texture scenes where even high-confidence primitives are ambiguous? The metrics (Chamfer distance, F-score) are standard but don’t capture perceptual quality—some reconstructions might be geometrically accurate but visually implausible.
Writing quality: The abstract and introduction oversell the “intrinsic solution” angle—it’s a good framing, but the actual method is still adding constraints, just at a different level. Section 3.2 (ambiguity indication) could be clearer about the gradient variance computation—is it per-parameter variance, or aggregated? The related work section is thorough but reads like a literature dump rather than positioning the work strategically. Rewriting the method section to lead with the sculptor metaphor would make the paper far more accessible.
Verdict: weak accept — Solid contribution with a useful insight (primitive-level ambiguity self-indication), but the method feels like a well-executed engineering solution rather than a fundamental rethinking. The experimental results are convincing, and the approach is practical.
Takeaways
Gradient variance as a confidence signal: If you’re training any differentiable representation (not just Gaussian Splatting), track per-parameter gradient variance across batches. High variance often means the parameter is underconstrained—the loss landscape is flat in that direction. You can use this to identify which parts of your model need stronger regularization or more data.
Primitive-level constraints beat global ones: When your representation is compositional (made of independent units like Gaussians, voxels, or patches), applying constraints at the unit level is more effective than global smoothness terms. Each unit can be ambiguous in different ways; global constraints average over these differences and miss the problem.
Opacity-geometry coupling is a design flaw: If you’re designing a 3D representation, don’t let opacity and position be independent. Tie them together—opaque primitives must be on surfaces, transparent ones can float. This isn’t just a regularization trick; it’s a structural constraint that reduces the solution space.
论文: 2605.12494 作者: Jiahe Li, Jiawei Zhang, Xiao Bai, Jin Zheng, Xiaohan Yu, Lin Gu, Gim Hee Lee 分类: cs.CV
缺口
NeRF 和高斯溅射等可微渲染方法推动了三维重建的发展,但它们撞上了一堵根本性的墙:光度歧义。
同一张图像可以由无穷多种几何-外观组合产生——明亮光线下的平坦白色表面看起来与昏暗光线下的凹凸灰色表面完全相同。
先前工作(NeuS、VolSDF、2DGS)试图用几何先验或正则化来约束这一问题,但这些都是外部的创可贴。
它们没有解决表示本身在基元层面就存在歧义的事实。
高斯溅射尤其脆弱。
每个高斯基元都有独立的不透明度和颜色,产生两种内置歧义:(1)不透明度-几何耦合——你无法判断表面是真实存在还是只是高度透明,(2)颜色-光照纠缠——那个亮度来自表面反照率还是光照?现有方法要么忽略这一点,要么应用不尊重每个基元歧义的全局约束。
光度歧义问题
       |
       v
   [图像 I = 几何 * 外观]
       |
       +---> 存在无穷多解
       |
       v
先前方法:              本文方法:
全局正则化        -->  基元级消歧
外部约束          -->  自指示机制
       |                    |
       v                    v
仍然歧义              确定表面
增量
一句话:AmbiSuR 之前,高斯溅射重建被未解决的基元级歧义产生的幻影几何所困扰;
之后,表示本身能够指示不确定的位置并自我纠正。
核心机制
AmbiSuR 分两个阶段运作。
首先,光度消歧约束了病态的几何问题。
对于每个高斯基元,它强制不透明度和几何必须对齐——如果一个基元声称是不透明的,其中心必须位于实际表面上,而不是悬浮在空间中。
这通过深度-法线对齐损失将不透明度值与几何一致性联系起来,打破了不透明度-几何歧义。
其次,歧义指示模块利用了高斯溅射的一个隐藏属性:约束不足(歧义)的基元在训练期间的梯度更新中自然表现出更高的方差。
该模块将这种方差作为置信度信号进行跟踪。
低置信度基元被标记,然后通过有针对性的几何细化进行纠正——调整它们的位置和尺度以匹配附近的高置信度几何。
输入:多视角图像
       |
       v
   [高斯溅射表示]
       |
       +---> 阶段1:光度消歧
       |         |
       |         +---> 不透明度-深度对齐
       |         +---> 法线一致性检查
       |         |
       |         v
       |     约束几何
       |
       +---> 阶段2:歧义指示
             |
             +---> 跟踪每个基元的梯度方差
             +---> 标记低置信度高斯
             +---> 细化被标记的基元
             |
             v
         纠正表面
把它想象成雕塑家用黏土工作。
黏土(高斯基元)可以塑造成任何形状,但有些区域是糊状且不稳定的(歧义)。
阶段1就像添加骨架——一个迫使黏土尊重底层结构的骨骼。
你不能随便堆黏土;
它必须遵循骨架的形状。
阶段2是雕塑家的手检查坚固度:按压每个点,如果它仍然柔软(高梯度方差),就重塑它以匹配附近的坚固区域。
黏土本身告诉你哪里需要更多工作。
关键概念
- 光度歧义:想象你在看一张球体的照片。
它是昏暗光线下的白色球体,还是明亮光线下的灰色球体?两者产生相同的图像。
在三维重建中,这意味着同一组照片可以由无穷多种形状(几何)和颜色(外观)的组合来解释。
数学没有足够的信息来选择一个答案。
传统方法添加额外的假设(平滑性、已知光照),但这些都是猜测。
AmbiSuR 转而查看表示的内部结构,找到歧义隐藏的地方并在那里解决它。
- 基元级歧义:高斯溅射将场景表示为数千个三维高斯斑点。
每个斑点都有自己的不透明度(透明程度)和颜色。
问题是:你可以通过使用许多堆叠的透明斑点,或更少的不透明斑点,使表面看起来相同。
同样,远处的明亮斑点可以看起来像近处的昏暗斑点。
这些不仅仅是理论问题——在训练期间,优化器会卡住,因为多个斑点配置产生相同的图像。
AmbiSuR 通过观察每个斑点的参数在训练期间如何抖动来识别这些卡住的配置。
- 自指示:这是巧妙的部分。
当一个高斯基元是歧义的(多个有效配置)时,它在训练期间的梯度是不一致的——一个批次更新将它推向左边,下一个推向右边。
梯度方向的高方差是歧义的症状。
AmbiSuR 不需要外部标签;
它将这种方差读取为置信度分数。
低置信度 = 歧义 = 需要纠正。
这就像一个金属探测器在不确定区域上发出更响的哔哔声,只不过信号来自优化过程本身。
框架转变
之前(2DGS、SuGaR):            之后(AmbiSuR):

多视角图像                       多视角图像
       |                                |
       v                                v
高斯溅射                         高斯溅射
       |                                |
       +---> 全局正则化                 +---> 每基元消歧
       |     (平滑表面)                 |     (不透明度-深度对齐)
       |                                |
       v                                +---> 梯度方差跟踪
歧义几何                                |     (自指示)
(幻影表面,                             |
 悬浮斑点)                              v
                                  确定表面
                                  (纠正的基元)
从全局平滑先验到基元级自诊断,核心转变是将歧义视为表示可以内部信号和纠正的每基元属性。
专家评审
选题眼光:真实且动机充分。
光度歧义不是小众问题——这是基于 NeRF 的方法在无纹理区域和镜面表面上挣扎的原因。
专注于高斯溅射的内置歧义是明智的;
该表示的流行使这立即相关。
将其框定为”内在解决方案”(修复表示本身)与”外在约束”(添加正则化)是真正的概念进步。
方法成熟度:光度消歧很直接——深度-法线对齐是一个已知的几何一致性检查,这里应用于基元级别。
新颖性在于歧义指示模块。
使用梯度方差作为置信度信号很巧妙,但论文没有深入证明为什么方差特别捕获歧义而不是其他训练不稳定性(噪声数据、学习率问题)。
细化步骤(纠正低置信度基元)感觉有些临时——它本质上是由置信度引导的空间平滑。
更有原则的方法可能会概率性地建模歧义。
实验诚意:强大的基线(2DGS、SuGaR、GOF)和多样化的数据集(DTU、Tanks and Temples、具有挑战性的真实世界扫描)。
消融研究隔离了每个组件的贡献。
然而,论文没有显示失败案例或讨论方法何时失效。
在极低纹理场景中会发生什么,即使高置信度基元也是歧义的?指标(Chamfer 距离、F-score)是标准的,但不能捕获感知质量——一些重建可能在几何上准确但视觉上不合理。
写作功力:摘要和引言过度推销”内在解决方案”角度——这是一个好的框架,但实际方法仍在添加约束,只是在不同的层面。
第3.2节(歧义指示)可以更清楚地说明梯度方差计算——是每参数方差,还是聚合的?相关工作部分很全面,但读起来像文献堆砌,而不是战略性地定位工作。
重写方法部分以雕塑家比喻开头会使论文更易于理解。
判决:弱接收 — 具有有用洞察(基元级歧义自指示)的扎实贡献,但方法感觉像是一个执行良好的工程解决方案,而不是根本性的重新思考。
实验结果令人信服,方法实用。
要点总结
梯度方差作为置信度信号:如果你正在训练任何可微表示(不仅仅是高斯溅射),跟踪跨批次的每参数梯度方差。
高方差通常意味着参数约束不足——损失景观在该方向上是平坦的。
你可以使用它来识别模型的哪些部分需要更强的正则化或更多数据。
基元级约束胜过全局约束:当你的表示是组合的(由独立单元组成,如高斯、体素或补丁),在单元级别应用约束比全局平滑项更有效。
每个单元可以以不同的方式歧义;
全局约束对这些差异进行平均并错过问题。
不透明度-几何耦合是设计缺陷:如果你正在设计三维表示,不要让不透明度和位置独立。
将它们联系在一起——不透明基元必须在表面上,透明基元可以悬浮。
这不仅仅是正则化技巧;
这是一个减少解空间的结构约束。