Paper: 2604.25887 Authors: Anas Gamal Aly, Hala ElAarag Categories: cs.CV, cs.AI, cs.RO, eess.SY
The Gap
Traffic signals have been adaptive for vehicles since the 1980s—loop detectors sense cars and adjust timing. But pedestrian signals remain stuck in the fixed-timer era. Press the button, get your 20 seconds, and the light changes whether you’ve finished crossing or not. This works fine for able-bodied adults walking at 1.2 m/s, but elderly pedestrians average 0.9 m/s, wheelchair users 0.8 m/s, and someone checking their phone might drop to 0.6 m/s. Prior work on pedestrian detection focused on collision avoidance for autonomous vehicles or counting foot traffic for urban planning—not real-time intervention in signal timing.
The gap: no deployed system monitors individual pedestrian progress during crossing and extends the signal when someone is moving too slowly to finish in time.
Problem: Fixed pedestrian timers strand slow walkers
   |
   v
Assumption: Real-time tracking can identify at-risk pedestrians
   |
   v
Method: YOLOv12 detection + ByteTrack + adaptive controller
   |
   v
Evidence: 71.4% reduction in stranding (9.10% -> 2.60%)
   |
   v
Conclusion: Vision-based adaptive signals are feasible and effective
The Increment
One sentence: Before this paper, pedestrian signals were blind timers; after, they can see who’s still in the crosswalk and wait for them.
Core Mechanism
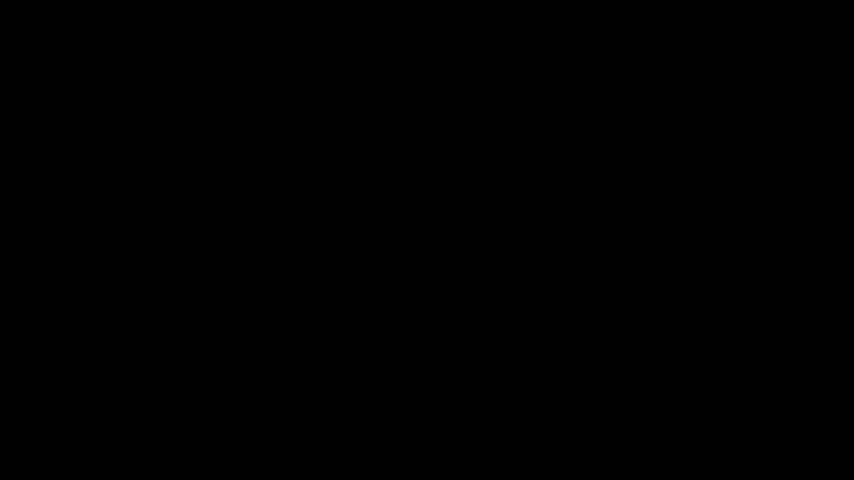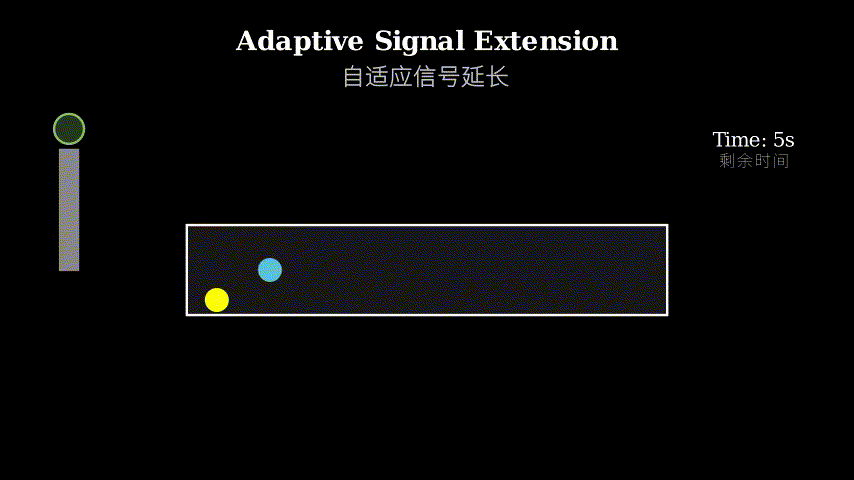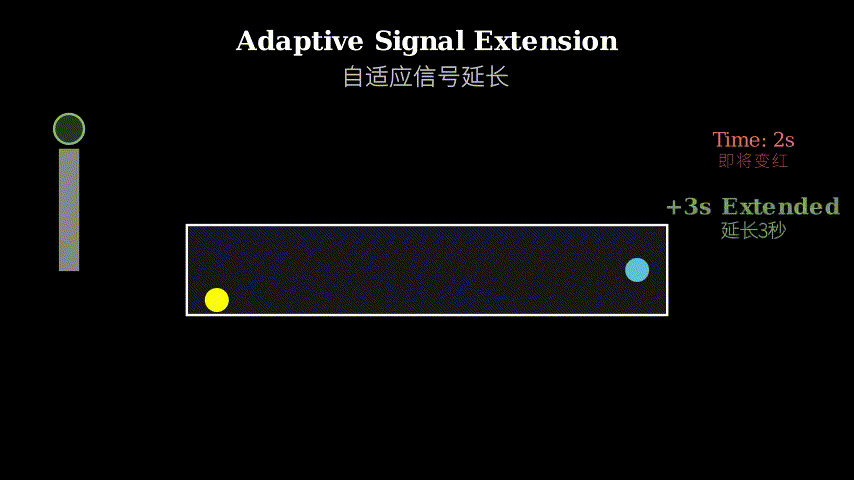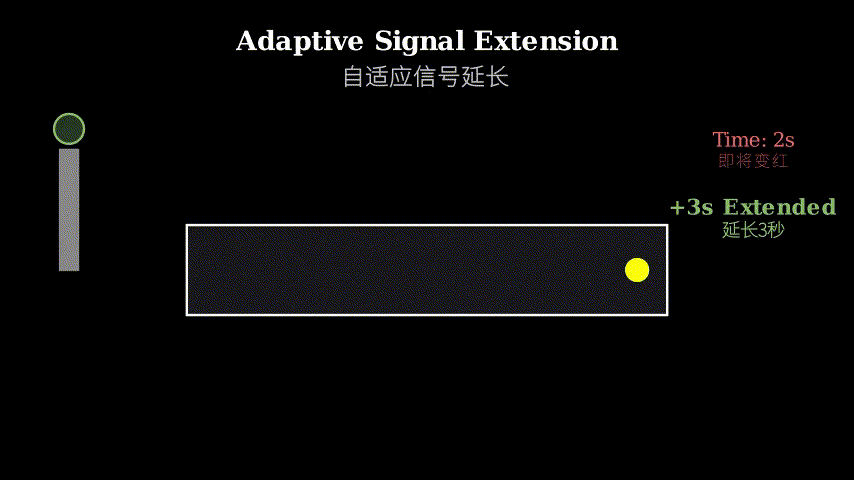
NPLB has three stages running in a pipeline. First, YOLOv12 processes each video frame from a crosswalk camera and outputs bounding boxes around detected pedestrians with confidence scores. Second, ByteTrack takes these detections and maintains persistent IDs for each person across frames, tracking their position over time even through brief occlusions. Third, an adaptive controller monitors the tracked positions: when the pedestrian signal countdown drops below a threshold (say, 5 seconds remaining) and any pedestrian is still more than 2 meters from the curb, it sends an extension command to the traffic signal controller, adding 5-10 seconds to the phase.
The system runs at 30 FPS on edge hardware. YOLOv12 was fine-tuned on the BGVP dataset (a collection of crosswalk videos with annotated pedestrians in various lighting and weather conditions). ByteTrack uses a Kalman filter to predict pedestrian motion between frames and matches detections using IoU (intersection over union) of bounding boxes. The controller uses simple geometric rules: calculate distance from bounding box center to the far curb, estimate time needed at average walking speed, compare to remaining signal time.
Camera Feed (30 FPS)
   |
   v
+------------------+
| YOLOv12 Detector |  <-- Fine-tuned on BGVP dataset
+------------------+
   |
   | Bounding boxes + confidence scores
   v
+------------------+
| ByteTrack        |  <-- Kalman filter + IoU matching
| (Multi-object    |
|  tracking)       |
+------------------+
   |
   | Tracked pedestrian positions + IDs
   v
+---------------------+
| Adaptive Controller |  <-- Distance check + time estimate
+---------------------+
   |
   | Extension signal (if needed)
   v
Traffic Signal Controller
Think of NPLB as a lifeguard watching a swimming pool. The detector (YOLOv12) is the lifeguard’s eyes, scanning the water and spotting each swimmer. The tracker (ByteTrack) is the lifeguard’s memory, keeping tabs on which swimmer is which even when they dip underwater briefly. The controller is the lifeguard’s judgment: if someone is still in the deep end when the pool is about to close, blow the whistle and keep the pool open a bit longer. The lifeguard doesn’t need to know why someone is swimming slowly—maybe they’re tired, maybe they’re helping a child—just that they need more time. Similarly, NPLB doesn’t classify pedestrians as “elderly” or “disabled”; it just measures: are you still in the crosswalk when time is running out?
Key Concepts
-
Multi-object tracking (MOT): Imagine watching a crowded dance floor from above. You can see people moving, but if you blink, can you tell which person is which when you open your eyes? MOT solves this by giving each person a persistent ID. ByteTrack does this by predicting where each person will be in the next frame (using their velocity from previous frames) and matching new detections to predictions. If a detection is close to a prediction, it’s probably the same person. If someone is briefly hidden behind another person (occlusion), ByteTrack keeps their ID alive for a few frames, waiting for them to reappear. This matters for NPLB because you need to know if the person near the curb now is the same person who was in the middle of the crosswalk 3 seconds ago—otherwise you might extend the signal for someone who already finished crossing.
-
[email protected] (mean Average Precision at 50% IoU): This is how we measure detector quality. IoU (intersection over union) compares a predicted bounding box to the ground truth: if they overlap by 50% or more, it counts as a correct detection. Precision is: of all the boxes you drew, how many were correct? Average Precision summarizes precision across different confidence thresholds. mAP averages this across all object classes. YOLOv12’s 0.756 [email protected] means that 75.6% of its high-confidence pedestrian boxes overlap ground truth by at least half—good enough for tracking, though it will miss some people and occasionally hallucinate a pedestrian where there’s a trash can.
-
Adaptive signal control: Traditional traffic signals run on fixed cycles: 60 seconds green for cars, 20 seconds for pedestrians, repeat. Adaptive control breaks the cycle when needed. Vehicle-adaptive signals (common since the 1990s) use loop detectors in the pavement to sense waiting cars and adjust green time. NPLB does the same for pedestrians but uses vision instead of loops. The key constraint: you can’t extend the pedestrian phase indefinitely or cross-traffic backs up. NPLB’s controller only extends when (1) someone is still crossing AND (2) time is almost up, limiting extensions to 12.1% of cycles in their simulations.
Framework Shift
Before (fixed timers):              After (NPLB):

Press button                        Press button
    |                                   |
    v                                   v
+--------+                          +--------+
| Timer  |                          | Timer  |
| starts |                          | starts |
+--------+                          +--------+
    |                                   |
    | 20 seconds                        | 20 seconds
    v                                   v
Light changes                       Camera watching
(regardless of                          |
 pedestrian                             | Still crossing?
 position)                              v
                                    +---------+
                                    | Extend? |
                                    +---------+
                                       / \
                                  Yes /   \ No
                                     /     \
                                    v       v
                              +5-10 sec   Light changes
From blind countdown to vision-guided patience, the core shift is treating pedestrian crossing time as a variable to optimize, not a constant to enforce.
Expert Assessment
Problem choice: Real gap. The elderly and disabled advocacy groups have complained about this for decades. The problem is well-documented (MUTCD guidelines acknowledge it but offer no solution beyond “make the timer longer,” which delays traffic for everyone). This paper attacks a genuine safety issue that existing adaptive signal research ignored because it focused on vehicle throughput.
Method maturity: Straightforward engineering, not a research breakthrough. YOLOv12 is off-the-shelf, ByteTrack is standard MOT, and the controller is a few if-statements. The contribution is integration and deployment thinking, not algorithmic novelty. That’s fine—sometimes the gap is “no one built the obvious thing.” But the paper oversells the detector comparison (5 models tested, YOLOv12 wins) as if this were a core contribution when it’s really just due diligence.
Experimental integrity: The Monte Carlo simulations are the weak link. They assume pedestrian speeds drawn from distributions (elderly: 0.9 m/s ± 0.2, etc.) but don’t model pedestrian behavior realistically. Real people speed up when they see the countdown, or freeze in the middle if they think they won’t make it. The 71.4% improvement is probably real but the exact number is suspect. The paper also doesn’t test on real intersections—just simulations fed with BGVP video. Where’s the pilot deployment? The baselines are fair (fixed timer vs. NPLB) but limited (no comparison to simpler heuristics like “extend if any motion detected in crosswalk”).
Writing quality: The related work section is a laundry list of pedestrian detection papers with no critical synthesis. The method section is clear but repetitive (the controller logic is explained three times in slightly different words). The results section front-loads the good news (71.4% reduction!) and buries the failure modes (what happens in heavy rain? at night?). Rewriting the evaluation section to lead with limitations and then show how the system performs despite them would make this more credible.
Verdict: Weak accept — solid engineering work addressing a real problem, but the evaluation needs real-world validation before this is deployment-ready.
Takeaways
Steal the two-threshold trick: NPLB uses separate thresholds for detection confidence (0.5) and tracking persistence (keep ID alive for 30 frames even if confidence drops). This is a general pattern for any vision system that needs to be conservative about false positives but robust to brief occlusions. In your own work, tune detection and tracking thresholds independently.
The “time-to-safety” metric: Instead of classifying people (elderly? disabled?), NPLB just measures: will you reach safety in time? This reframes the problem from demographic prediction (hard, privacy-invasive) to geometric prediction (easy, privacy-preserving). Applicable anywhere you’re tempted to classify users when you really just need to predict an outcome.
Edge deployment constraints shape algorithm choice: The paper chose YOLOv12 over Faster R-CNN not because it’s more accurate (it’s not, by much) but because it runs at 30 FPS on a Jetson Xavier. This is the right way to pick models for real-time systems—latency and throughput matter more than the last 2% of mAP. If you’re building something that needs to react in real-time, benchmark on target hardware first, then optimize accuracy within your latency budget.
论文: 2604.25887 作者: Anas Gamal Aly, Hala ElAarag 分类: cs.CV, cs.AI, cs.RO, eess.SY
缺口
交通信号灯从1980年代起就对车辆自适应了——地感线圈检测车辆并调整配时。
但行人信号灯还停留在固定计时器时代。
按下按钮,给你20秒,不管你走没走完,灯就变了。
这对健全成年人没问题(步速1.2米/秒),但老年人平均0.9米/秒,轮椅使用者0.8米/秒,看手机的人可能降到0.6米/秒。
此前关于行人检测的研究聚焦于自动驾驶的碰撞避免,或城市规划的人流统计——不是实时干预信号配时。
缺口在于:没有已部署的系统能在过街过程中监控单个行人的进度,并在有人走得太慢、来不及通过时延长信号。
问题:固定行人计时器让慢速行人滞留
   |
   v
假设:实时跟踪能识别高风险行人
   |
   v
方法:YOLOv12检测 + ByteTrack + 自适应控制器
   |
   v
证据:滞留率降低71.4%(9.10% -> 2.60%)
   |
   v
结论:基于视觉的自适应信号可行且有效
增量
一句话:这篇论文之前,行人信号灯是盲目的计时器;
之后,它们能看见谁还在人行横道上,并等他们过完。
核心机制
NPLB有三个阶段组成流水线。
第一阶段,YOLOv12处理人行横道摄像头的每一帧视频,输出检测到的行人边界框和置信度分数。
第二阶段,ByteTrack接收这些检测结果,为每个人维护跨帧的持久ID,即使短暂遮挡也能跟踪他们的位置。
第三阶段,自适应控制器监控被跟踪的位置:当行人信号倒计时低于阈值(比如还剩5秒)且任何行人距离路缘还有2米以上时,它向交通信号控制器发送延长命令,增加5-10秒的相位时间。
系统在边缘硬件上以30帧/秒运行。
YOLOv12在BGVP数据集(包含各种光照和天气条件下标注了行人的人行横道视频集合)上微调。
ByteTrack使用卡尔曼滤波器预测帧间行人运动,用边界框的IoU(交并比)匹配检测结果。
控制器使用简单的几何规则:计算边界框中心到远端路缘的距离,按平均步速估算所需时间,与剩余信号时间比较。
摄像头视频流(30帧/秒)
   |
   v
+------------------+
| YOLOv12 检测器   |  <-- 在BGVP数据集上微调
+------------------+
   |
   | 边界框 + 置信度分数
   v
+------------------+
| ByteTrack        |  <-- 卡尔曼滤波 + IoU匹配
| (多目标跟踪)   |
+------------------+
   |
   | 被跟踪的行人位置 + ID
   v
+---------------------+
| 自适应控制器        |  <-- 距离检查 + 时间估算
+---------------------+
   |
   | 延长信号(如需要)
   v
交通信号控制器
把NPLB想象成看守游泳池的救生员。
检测器(YOLOv12)是救生员的眼睛,扫视水面,发现每个游泳者。
跟踪器(ByteTrack)是救生员的记忆,记住哪个游泳者是哪个,即使他们短暂潜入水下。
控制器是救生员的判断:如果泳池快关门时还有人在深水区,吹哨子,让泳池再开一会儿。
救生员不需要知道为什么有人游得慢——也许累了,也许在帮孩子——只需要知道他们需要更多时间。
同样,NPLB不把行人分类为”老年人”或”残疾人”;
它只测量:时间快到时你还在人行横道上吗?
关键概念
- 多目标跟踪(MOT):想象从上方看一个拥挤的舞池。
你能看到人在移动,但如果你眨眼,睁眼后能分清哪个人是哪个吗?
MOT通过给每个人一个持久ID来解决这个问题。
ByteTrack通过预测每个人在下一帧的位置(用他们前几帧的速度)并将新检测结果匹配到预测来做到这一点。
如果检测结果接近预测,很可能是同一个人。
如果有人短暂被另一个人挡住(遮挡),ByteTrack会让他们的ID存活几帧,等他们重新出现。
这对NPLB很重要,因为你需要知道现在靠近路缘的人是不是3秒前在人行横道中间的那个人——否则你可能为已经过完街的人延长信号。
- [email protected](50% IoU下的平均精度均值):这是我们衡量检测器质量的方式。
IoU(交并比)比较预测边界框和真实标注:如果它们重叠50%或以上,算作正确检测。
精度是:你画的所有框中,有多少是正确的?
平均精度总结了不同置信度阈值下的精度。
mAP对所有目标类别求平均。
YOLOv12的0.756 [email protected]意味着它75.6%的高置信度行人框与真实标注至少重叠一半——对跟踪来说足够好,虽然会漏掉一些人,偶尔把垃圾桶误认为行人。
- 自适应信号控制:传统交通信号灯按固定周期运行:车辆绿灯60秒,行人20秒,重复。
自适应控制在需要时打破周期。
车辆自适应信号(1990年代以来常见)用路面地感线圈检测等待的车辆并调整绿灯时间。
NPLB对行人做同样的事,但用视觉代替地感线圈。
关键约束:你不能无限延长行人相位,否则交叉交通会堵塞。
NPLB的控制器只在(1)有人还在过街且(2)时间快到时才延长,在他们的模拟中将延长限制在12.1%的周期内。
框架转变
之前(固定计时器):            之后(NPLB):

按下按钮                        按下按钮
    |                               |
    v                               v
+--------+                      +--------+
| 计时器 |                      | 计时器 |
| 启动   |                      | 启动   |
+--------+                      +--------+
    |                               |
    | 20秒                          | 20秒
    v                               v
灯变了                          摄像头监视
(不管行人                          |
 位置)                             | 还在过街?
                                    v
                                +---------+
                                | 延长?  |
                                +---------+
                                   / \
                              是  /   \ 否
                                 /     \
                                v       v
                          +5-10秒     灯变了
从盲目倒计时到视觉引导的耐心,核心转变是把行人过街时间当作可优化的变量,而非要强制执行的常量。
专家评审
选题眼光:真实缺口。
老年人和残疾人权益团体抱怨这个问题几十年了。
问题有充分记录(MUTCD指南承认这个问题但除了”把计时器调长”没有解决方案,而那会让所有人的交通都延误)。
这篇论文攻击了一个真实的安全问题,现有的自适应信号研究忽略了它,因为它们专注于车辆通行量。
方法成熟度:直接的工程,不是研究突破。
YOLOv12是现成的,ByteTrack是标准MOT,控制器是几个if语句。
贡献在于集成和部署思考,不是算法创新。
这没问题——有时缺口就是”没人造这个显而易见的东西”。
但论文过度推销检测器比较(测试了5个模型,YOLOv12获胜),好像这是核心贡献,其实只是尽职调查。
实验诚意:蒙特卡洛模拟是薄弱环节。
它们假设行人速度从分布中抽取(老年人:0.9米/秒±0.2等),但没有真实地建模行人行为。
真实的人看到倒计时会加速,或者如果觉得来不及会在中间停住。
71.4%的改进可能是真的,但确切数字可疑。
论文也没在真实路口测试——只是用BGVP视频喂给模拟。
试点部署在哪里?
基线是公平的(固定计时器vs NPLB)但有限(没有与更简单的启发式比较,比如”如果人行横道检测到任何运动就延长”)。
写作功力:相关工作部分是行人检测论文的清单,没有批判性综合。
方法部分清晰但重复(控制器逻辑用稍微不同的话解释了三遍)。
结果部分把好消息放前面(71.4%降低!
)把失败模式埋起来(大雨时怎么办?
夜间呢?
)。
重写评估部分,先讲局限性,再展示系统尽管有这些局限性仍表现如何,会让这篇论文更可信。
判决:弱接收——解决真实问题的扎实工程工作,但评估需要真实世界验证才能准备好部署。
要点总结
偷走双阈值技巧:NPLB对检测置信度(0.5)和跟踪持久性(即使置信度下降也保持ID存活30帧)使用单独的阈值。
这是任何需要对假阳性保守但对短暂遮挡鲁棒的视觉系统的通用模式。
在你自己的工作中,独立调整检测和跟踪阈值。
“到达安全的时间”指标:NPLB不分类人(老年人?
残疾人?
),只测量:你能及时到达安全地带吗?
这把问题从人口统计预测(困难、侵犯隐私)重新框定为几何预测(容易、保护隐私)。
适用于任何你想分类用户但实际上只需要预测结果的地方。
边缘部署约束塑造算法选择:论文选择YOLOv12而非Faster R-CNN不是因为它更准确(差不多),而是因为它在Jetson Xavier上以30帧/秒运行。
这是为实时系统选择模型的正确方式——延迟和吞吐量比最后2%的mAP更重要。
如果你在构建需要实时反应的东西,先在目标硬件上做基准测试,然后在延迟预算内优化准确性。