Paper: 2605.30335 Authors: Anany Kotawala Categories: cs.AI, cs.CL
The Gap
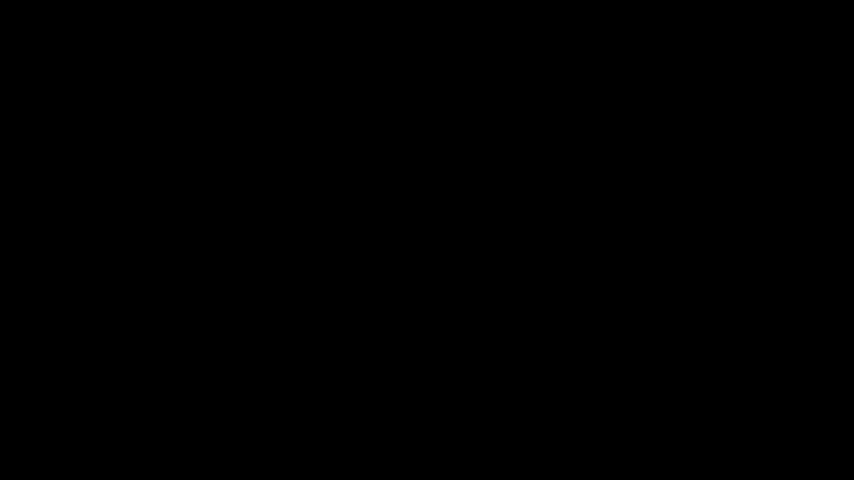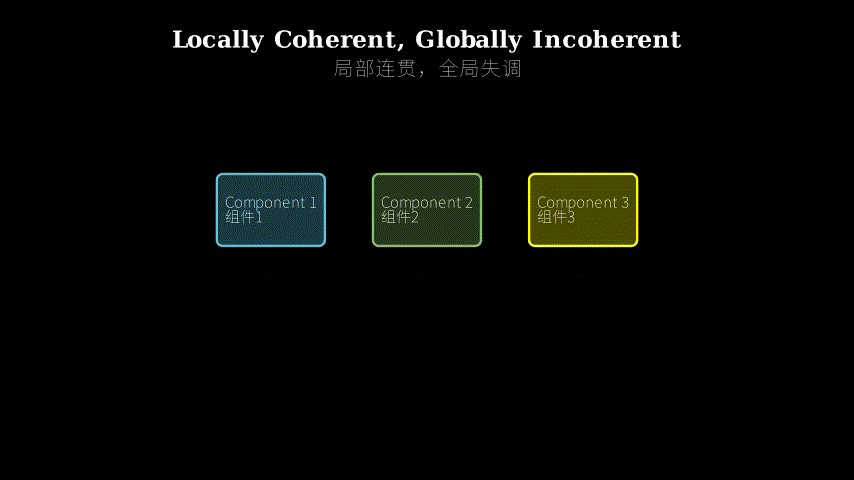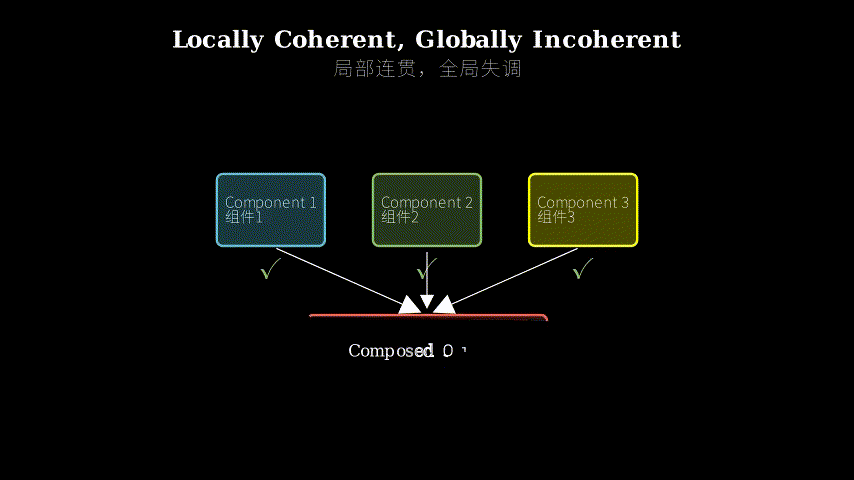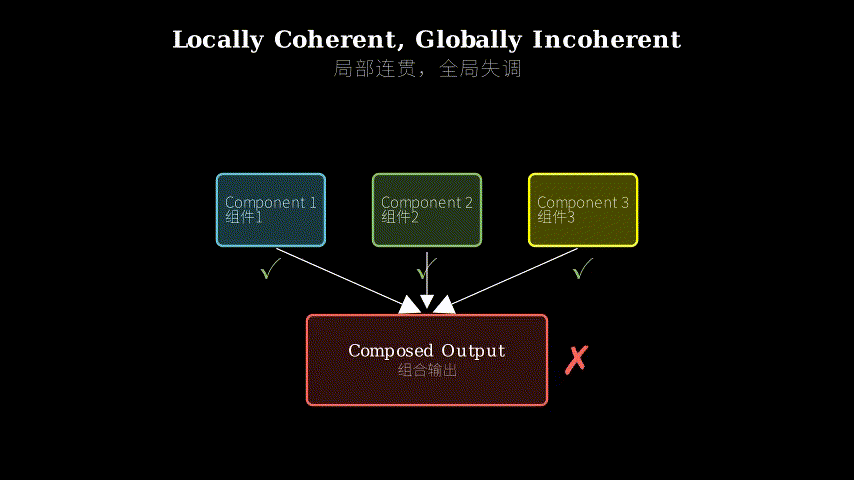
Multi-component LLM systems (retrieval-augmented generation, agent ensembles, modular pipelines) are everywhere. Each component produces probabilistic outputs that are locally coherent—they satisfy probability axioms within their own scope. The assumption: if every part is coherent, the whole is coherent. Prior work on LLM calibration and ensemble methods focuses on improving individual component accuracy or aggregation rules, but assumes the composition inherits coherence from its parts.
This paper identifies a structural failure: when components see different slices of a joint problem and their outputs are composed, the result can violate basic probability axioms (e.g., probabilities summing to more than 1, contradictory conditional dependencies) even when every component is individually coherent. No existing framework measures or bounds this compositional incoherence at runtime.
Problem: Multi-component LLM agents
   |
   v
Assumption: Local coherence -> Global coherence
   |
   v
Reality: Composition violates probability axioms
   |
   v
Method: Formalize compositional residual eps*
        (L2 distance to coherent polytope)
   |
   v
Evidence: eps* > 0 on 33-94% of cliques
          +0.115 nats regret per bet
   |
   v
Conclusion: Local coherence does NOT suffice
            Intuitive mitigations FAIL
The Increment
One sentence: Before this paper, we assumed multi-component LLM systems inherit coherence from their parts; after, we know they systematically violate probability axioms and can quantify the violation at runtime.
Core Mechanism
The method has three layers. First, formalization: define the compositional residual eps** as the L2 distance from the composed probability distribution (what the system outputs) to the nearest point in the coherent polytope (the set of all distributions satisfying probability axioms given the declared cross-component constraints). This is computable at runtime from system output alone.
Second, characterization: establish a product-structure dichotomy. When components are independent (product structure), local coherence guarantees global coherence (eps** = 0). When components share variables (coupled structure), local coherence does NOT suffice. A Rayleigh-quotient predictor estimates eps* from the coupling structure before running the system, matching observed residuals within 7% on three of four relation classes.
Third, repair and monitoring: a hierarchical Boyle-Dykstra projection algorithm takes the incoherent composition and projects it onto the coherent polytope deterministically. An anytime-valid e-process provides sequential coherence monitoring—detecting when the system drifts into incoherence during a multi-turn interaction.
Input: Component outputs (local coherent distributions)
  |
  v
[Compose] --> Composed distribution Q
  |
  v
[Measure] --> eps* = distance(Q, coherent polytope)
  |
  v
[Predict] --> Rayleigh quotient estimates eps* from structure
  |
  v
[Repair] --> Boyle-Dykstra projection --> Q' (coherent)
  |
  v
[Monitor] --> e-process tracks coherence over time
Think of it like building a bridge from modular sections. Each section (component) is structurally sound when tested in isolation—bolts tight, welds clean, load-bearing capacity verified. You assume the assembled bridge inherits this soundness. But when you bolt the sections together, the joints don’t align perfectly. The cumulative misalignment creates stress concentrations that violate the bridge’s load-bearing assumptions, even though every section passed inspection.
The compositional residual eps* is the total misalignment at the joints. The product-structure dichotomy says: if sections are independent (no shared load paths), misalignment doesn’t propagate. If sections share load (coupled structure), misalignment compounds. The Rayleigh quotient predicts misalignment from the blueprint before assembly. The Boyle-Dykstra projection is the hydraulic jack that forces the joints into alignment. The e-process is the strain gauge that monitors alignment during operation.
Key Concepts
-
Coherent polytope: Imagine all possible probability distributions over a set of events as points in a high-dimensional space. Not all points are valid—some violate basic rules like “probabilities must sum to 1” or “if A implies B, then P(A) ≤ P(B).” The coherent polytope is the subset of points that satisfy all probability axioms and the declared constraints between components. It’s a convex region: if two distributions are coherent, any weighted average of them is also coherent. The compositional residual eps** measures how far outside this region the composed distribution lands. Concrete example: Component A says P(rain) = 0.6, Component B says P(rain AND cold) = 0.5. If they’re composed naively, you might output both claims. But P(rain AND cold) cannot exceed P(rain), so the composition is outside the coherent polytope. The distance to the nearest valid point (e.g., adjusting to P(rain) = 0.6, P(rain AND cold) = 0.5) is eps*.
-
Product-structure dichotomy: This is the paper’s central theoretical result. If components operate on disjoint variable sets (product structure), their joint distribution is the product of their marginals, and local coherence guarantees global coherence. If components share variables (coupled structure), the joint distribution must satisfy cross-component constraints (e.g., marginalization, conditional independence), and local coherence does NOT guarantee global coherence. Example: Two weather forecasters, one predicting rain (yes/no), one predicting temperature (hot/cold). If they’re independent (product structure), their joint forecast is automatically coherent. If they share a variable (e.g., both predict “rain” but use different definitions), their forecasts can contradict even if each is individually coherent.
-
Rayleigh quotient predictor: Before running the system, you can estimate eps** from the coupling structure alone. The Rayleigh quotient is a ratio: (variance of constraint violations) / (total variance). It captures how much of the system’s uncertainty is concentrated in the cross-component constraints versus within-component uncertainty. High Rayleigh quotient → high predicted eps*. The paper shows this predictor matches observed eps* within 7% on three of four relation classes, meaning you can anticipate compositional incoherence from the system architecture before deployment.
Framework Shift
Before (mainstream approach):        After (this paper):

Component A --> [Aggregate] --> Output    Component A --+
Component B ----^                         Component B --|--[Compose]--> Q
Component C ----^                         Component C --+       |
                                                                v
Assumption: If A, B, C coherent,                      [Measure eps*]
            output coherent                                     |
                                                                v
Focus: Improve A, B, C individually              eps* > 0? --> [Repair via projection]
       or aggregation rule                                     |
                                                                v
                                                       Q' (coherent output)
                                                                +
                                                       [Monitor via e-process]
One sentence: From assuming composition inherits coherence to measuring and repairing compositional incoherence as a first-class system property.
Expert Assessment
Problem choice: Real gap. Multi-component LLM systems are production reality (RAG, agent frameworks, ensemble forecasting), and the assumption that local coherence suffices is implicit everywhere. The paper makes the invisible visible. It sits at the intersection of probabilistic reasoning and LLM system design—a natural next question after calibration research.
Method maturity: The formalization (eps** as L2 distance to coherent polytope) is clean and computable. The product-structure dichotomy is a genuine theoretical contribution. The Rayleigh quotient predictor is clever—predicting failure from structure alone is valuable. The Boyle-Dykstra projection is borrowed from convex optimization, not novel, but appropriately applied. The negative results (three intuitive mitigations all fail) are as important as the positive results. No simpler approach is being overlooked; the problem requires this level of machinery.
Experimental integrity: The setup is honest. Four mid-tier LLMs, 1,876 ensemble cliques, 1,770 resolved bets. The baselines (retrieval, partition-aware prompting, aggregator-LLM) are the obvious things practitioners would try, and the paper shows they don’t work. The +0.115 nats regret is meaningful in forecasting contexts. One concern: the gain collapses to +0.006 when bettors themselves coherentize, suggesting the problem might be less severe in adversarial settings where downstream users apply their own coherence checks. The paper acknowledges this but doesn’t explore it deeply. The frontier-panel rerun (Section 5.5) is mentioned but not detailed in the abstract, which is a writing choice that hides potentially important results.
Writing quality: The abstract is dense and assumes familiarity with coherence theory and betting markets. The paper would benefit from a concrete running example in the introduction—show a real multi-component LLM system producing an incoherent output, compute eps**, apply the repair, and show the before/after. The formalization is rigorous but could use more intuition-building before diving into polytopes and Rayleigh quotients. The negative results section (mitigations that fail) is the most valuable part and should be elevated.
Verdict: weak accept — Identifies a real, underexplored failure mode in production LLM systems and provides both theory and runtime tools to address it, but the writing assumes too much background and the practical impact depends on deployment context.
Takeaways
For practitioners building multi-component LLM systems: Don’t assume your ensemble is coherent just because each component is calibrated. Compute eps** at runtime (the paper provides the formula). If eps* > 0, apply the Boyle-Dykstra projection before serving the output. This is especially critical for forecasting, decision support, or any application where probabilistic outputs are consumed by downstream reasoning.
For researchers: The product-structure dichotomy is a transferable insight. Any modular probabilistic system (not just LLMs) can exhibit this failure. The Rayleigh quotient predictor is a general tool for anticipating compositional failures from architecture alone—useful for system design and ablation studies.
For system designers: The three failed mitigations (retrieval, partition-aware prompting, aggregator-LLM) are instructive. Giving components more context or adding a meta-component doesn’t fix the structural problem. The failure is in the composition operator, not the components. Design your aggregation layer to enforce coherence constraints explicitly, not implicitly.
Steal this: The e-process for sequential coherence monitoring. If you’re building a multi-turn agent system, this gives you a principled way to detect when the agent’s beliefs are drifting into incoherence over time, which is a leading indicator of downstream failures.
论文: 2605.30335 作者: Anany Kotawala 分类: cs.AI, cs.CL
缺口
多组件LLM系统(检索增强生成、智能体集成、模块化流水线)无处不在。
每个组件产生局部连贯的概率输出——在自己的范围内满足概率公理。
假设是:如果每个部分都连贯,整体就连贯。
此前关于LLM校准和集成方法的工作专注于提高单个组件的准确性或聚合规则,但假设组合从其组成部分继承连贯性。
本文识别出一个结构性失效:当组件看到联合问题的不同切片并组合它们的输出时,即使每个组件单独都是连贯的,结果也可能违反基本概率公理(例如,概率和超过1,矛盾的条件依赖)。
现有框架无法在运行时测量或限定这种组合不一致性。
问题:多组件LLM智能体
   |
   v
假设:局部连贯 -> 全局连贯
   |
   v
现实:组合违反概率公理
   |
   v
方法:形式化组合残差 eps*
     (到连贯多面体的L2距离)
   |
   v
证据:33-94%的团簇上 eps* > 0
      每次下注 +0.115 nats 遗憾
   |
   v
结论:局部连贯不足够
      直觉性缓解方法失败
增量
一句话: 这篇论文之前,我们假设多组件LLM系统从其组成部分继承连贯性;
之后,我们知道它们系统性地违反概率公理,并且可以在运行时量化这种违反。
核心机制
方法有三层。
第一,形式化:将组合残差 eps** 定义为从组合概率分布(系统输出的内容)到连贯多面体(给定声明的跨组件约束,满足概率公理的所有分布的集合)中最近点的L2距离。
这可以仅从系统输出在运行时计算。
第二,刻画:建立积结构二分法。
当组件独立时(积结构),局部连贯保证全局连贯(eps* = 0)。
当组件共享变量时(耦合结构),局部连贯不足够。
Rayleigh商预测器在运行系统之前从耦合结构估计 eps*,在四个关系类中的三个上与观察到的残差匹配在7%以内。
第三,修复和监控:分层Boyle-Dykstra投影算法接受不连贯的组合并将其确定性地投影到连贯多面体上。
任意时间有效的e-过程提供顺序连贯性监控——在多轮交互期间检测系统何时漂移到不连贯状态。
输入:组件输出(局部连贯分布)
  |
  v
[组合] --> 组合分布 Q
  |
  v
[测量] --> eps* = distance(Q, 连贯多面体)
  |
  v
[预测] --> Rayleigh商从结构估计 eps*
  |
  v
[修复] --> Boyle-Dykstra投影 --> Q'(连贯)
  |
  v
[监控] --> e-过程跟踪时间上的连贯性
把它想象成用模块化部件建造桥梁。
每个部件(组件)在隔离测试时结构健全——螺栓拧紧,焊缝干净,承载能力验证通过。
你假设组装后的桥梁继承这种健全性。
但当你把部件螺栓连接在一起时,接头并不完美对齐。
累积的错位产生应力集中,违反桥梁的承载假设,即使每个部件都通过了检验。
组合残差 eps* 是接头处的总错位。
积结构二分法说:如果部件独立(没有共享载荷路径),错位不会传播。
如果部件共享载荷(耦合结构),错位会复合。
Rayleigh商在组装前从蓝图预测错位。
Boyle-Dykstra投影是强制接头对齐的液压千斤顶。
e-过程是在运行期间监控对齐的应变计。
关键概念
- 连贯多面体:想象一组事件上所有可能的概率分布作为高维空间中的点。
并非所有点都有效——有些违反基本规则,如”概率必须和为1”或”如果A蕴含B,则P(A) ≤ P(B)”。
连贯多面体是满足所有概率公理和组件间声明约束的点的子集。
它是一个凸区域:如果两个分布是连贯的,它们的任何加权平均也是连贯的。
组合残差 eps* 测量组合分布落在这个区域外多远。
具体例子:组件A说P(下雨) = 0.6,组件B说P(下雨且冷) = 0.5。
如果天真地组合它们,你可能输出两个声明。
但P(下雨且冷)不能超过P(下雨),所以组合在连贯多面体之外。
到最近有效点的距离(例如,调整为P(下雨) = 0.6,P(下雨且冷) = 0.5)就是 eps*。
- 积结构二分法:这是论文的核心理论结果。
如果组件在不相交的变量集上操作(积结构),它们的联合分布是其边缘分布的乘积,局部连贯保证全局连贯。
如果组件共享变量(耦合结构),联合分布必须满足跨组件约束(例如,边缘化,条件独立),局部连贯不保证全局连贯。
例子:两个天气预报员,一个预测降雨(是/否),一个预测温度(热/冷)。
如果它们独立(积结构),它们的联合预报自动连贯。
如果它们共享一个变量(例如,两者都预测”降雨”但使用不同定义),即使每个单独连贯,它们的预报也可能矛盾。
- Rayleigh商预测器:在运行系统之前,你可以仅从耦合结构估计 eps**。
Rayleigh商是一个比率:(约束违反的方差)/(总方差)。
它捕获系统的不确定性有多少集中在跨组件约束中,而不是组件内不确定性。
高Rayleigh商 → 高预测 eps*。
论文显示这个预测器在四个关系类中的三个上与观察到的 eps* 匹配在7%以内,意味着你可以在部署前从系统架构预期组合不一致性。
框架转变
之前(主流方法):                之后(本文方法):

组件A --> [聚合] --> 输出          组件A --+
组件B ----^                       组件B --|--[组合]--> Q
组件C ----^                       组件C --+       |
                                                  v
假设:如果A、B、C连贯,                      [测量 eps*]
      输出连贯                                    |
                                                  v
焦点:单独改进A、B、C              eps* > 0? --> [通过投影修复]
      或聚合规则                                  |
                                                  v
                                         Q'(连贯输出)
                                                  +
                                         [通过e-过程监控]
一句话:从假设组合继承连贯性到测量和修复组合不一致性作为一等系统属性。
专家评审
选题眼光:真实缺口。
多组件LLM系统是生产现实(RAG、智能体框架、集成预测),局部连贯足够的假设在各处都是隐含的。
论文让不可见的变得可见。
它位于概率推理和LLM系统设计的交叉点——校准研究之后的自然下一个问题。
方法成熟度:形式化(eps** 作为到连贯多面体的L2距离)干净且可计算。
积结构二分法是真正的理论贡献。
Rayleigh商预测器巧妙——仅从结构预测失败是有价值的。
Boyle-Dykstra投影借用自凸优化,不新颖,但应用得当。
负面结果(三种直觉性缓解方法都失败)与正面结果同样重要。
没有被忽略的更简单方法;
问题需要这个级别的机制。
实验诚意:设置诚实。
四个中等层级LLM,1,876个集成团簇,1,770个已解决的赌注。
基线(检索、分区感知提示、聚合器LLM)是实践者会尝试的明显方法,论文显示它们不起作用。
+0.115 nats遗憾在预测上下文中是有意义的。
一个担忧:当下注者自己连贯化时,增益崩溃到+0.006,表明在下游用户应用自己的连贯性检查的对抗性设置中,问题可能不那么严重。
论文承认这一点但没有深入探索。
前沿面板重跑(第5.5节)被提及但在摘要中没有详细说明,这是一个写作选择,隐藏了潜在重要的结果。
写作功力:摘要密集,假设熟悉连贯性理论和博彩市场。
论文将受益于引言中的具体运行示例——展示一个真实的多组件LLM系统产生不连贯输出,计算 eps*,应用修复,并显示前后对比。
形式化严格但在深入多面体和Rayleigh商之前可以建立更多直觉。
负面结果部分(失败的缓解方法)是最有价值的部分,应该被提升。
判决:弱接收 — 识别出生产LLM系统中一个真实的、探索不足的失效模式,并提供理论和运行时工具来解决它,但写作假设了太多背景,实际影响取决于部署上下文。
要点总结
对于构建多组件LLM系统的实践者:不要仅仅因为每个组件都经过校准就假设你的集成是连贯的。
在运行时计算 eps*(论文提供公式)。
如果 eps* > 0,在提供输出之前应用Boyle-Dykstra投影。
这对于预测、决策支持或任何概率输出被下游推理消费的应用尤其关键。
对于研究者:积结构二分法是一个可迁移的洞见。
任何模块化概率系统(不仅仅是LLM)都可能表现出这种失效。
Rayleigh商预测器是一个通用工具,用于仅从架构预期组合失败——对系统设计和消融研究有用。
对于系统设计者:三个失败的缓解方法(检索、分区感知提示、聚合器LLM)具有启发性。
给组件更多上下文或添加元组件不能修复结构问题。
失效在组合算子中,而不是组件中。
设计你的聚合层以显式而非隐式地强制连贯性约束。
偷走这个:用于顺序连贯性监控的e-过程。
如果你正在构建多轮智能体系统,这给你一个原则性的方法来检测智能体的信念何时随时间漂移到不连贯状态,这是下游失败的领先指标。