Paper: 2606.12406 Authors: Steven Oh, Jason Jingzhou Liu, Tony Tao, Philip Han, Kenneth Shaw, Satoshi Funabashi, Ruslan Salakhutdinov, Deepak Pathak Categories: cs.RO, cs.AI, cs.LG, eess.SY
The Gap
Existing work on force-aware manipulation either assumes dedicated joint-torque sensors (e.g., KUKA iiwa, Franka Emika) or relies on model-based disturbance observers that require accurate dynamics models and system identification (e.g., De Luca et al., 2006; Wahrburg et al., 2018). For low-cost commodity robot arms (e.g., WidowX, Interbotix), these approaches fail: sensors are absent, and model-based methods degrade under unmodeled friction, backlash, and nonlinearities. The community has thus treated force feedback as a luxury for the rich.
This paper breaks that assumption by asking: can we learn to “feel” external forces using only the existing proprioceptive signals (joint positions, velocities, currents) from a cheap robot, with minimal data and training?
The logic chain:
Problem: Contact-rich manipulation without force sensors
   |
   v
Assumption: Low-cost arms lack torque sensors,
model-based observers are brittle
   |
   v
Method: Neural External Torque Estimation (NEXT)
trained on 10min free-motion data +
Force-Informed Re-Sampling Training (FIRST)
for policy learning
   |
   v
Evidence: 17% improvement over prior force-aware
policies on 5 long-horizon tasks;
estimates match dedicated sensor accuracy
   |
   v
Conclusion: Commodity arms can now do
force-aware teleoperation and policy learning
without hardware modification
The Increment
One sentence: Before this paper, force sensing on commodity arms required expensive hardware or fragile models; after this paper, a 1-minute neural network training + 10 minutes of waving the arm in free space gives you comparable torque estimation, unlocking force-feedback teleoperation and improved behavior cloning.
Core Mechanism
NEXT is a lightweight MLP that takes as input the current joint positions, velocities, and motor currents (easily readable on any robot) and outputs an estimated external torque for each joint. The training data is trivial to collect: simply move the robot arm freely in the air for 10 minutes, recording these signals. During free motion, the true external torque is zero (no contact), so the network learns to predict the null external torque from the arm’s own dynamics. At test time, any deviation from this learned baseline indicates an external disturbance.
Why does this work? Because the arm’s intrinsic torque — due to inertia, Coriolis, friction, gravity — is a deterministic function of the kinematic state and motor currents. The network implicitly learns this inverse dynamics mapping, using the motor current as a proxy for the motor torque command. The key insight is that the external torque is the residual: the difference between what the motors are actually doing (current) and what the dynamics model predicts they should be doing (learned from free motion). The network directly outputs that residual.
FIRST then uses the estimated torque signal to re-weight the training data for behavior cloning. In contact-rich tasks, the transition from “no contact” to “contact” (pre-contact and contact segments) is short but critical. Prior BC methods either train on all transitions equally or use hand-crafted heuristics. FIRST up-samples these segments by a factor proportional to the detected external torque magnitude, forcing the policy to focus on the delicate force-torque interactions right before and during contact.
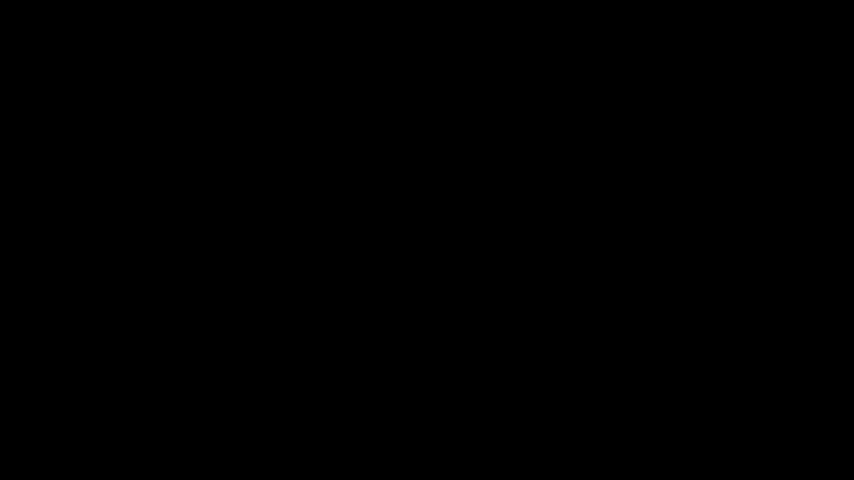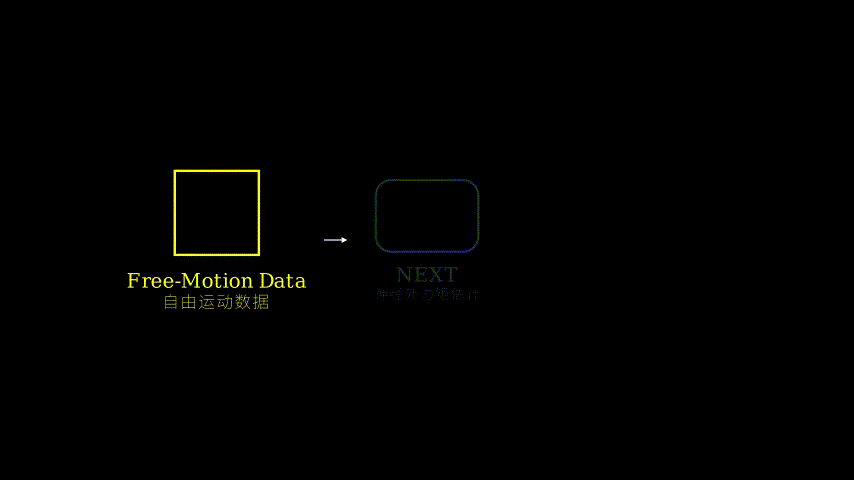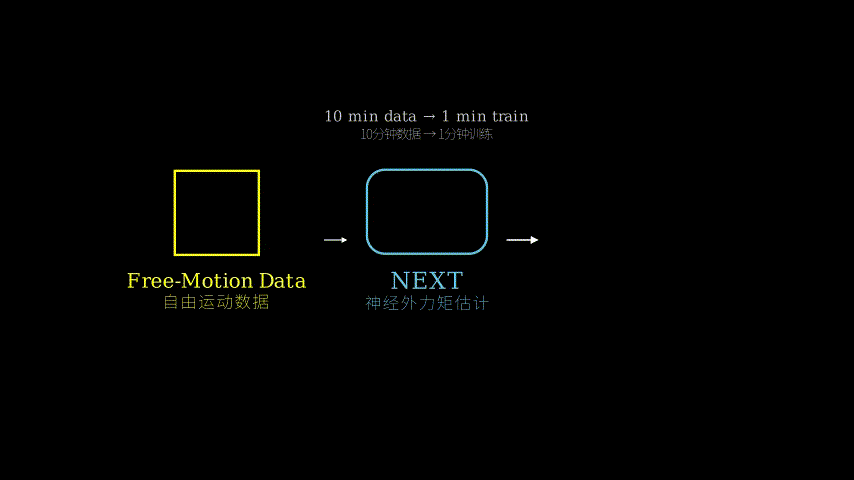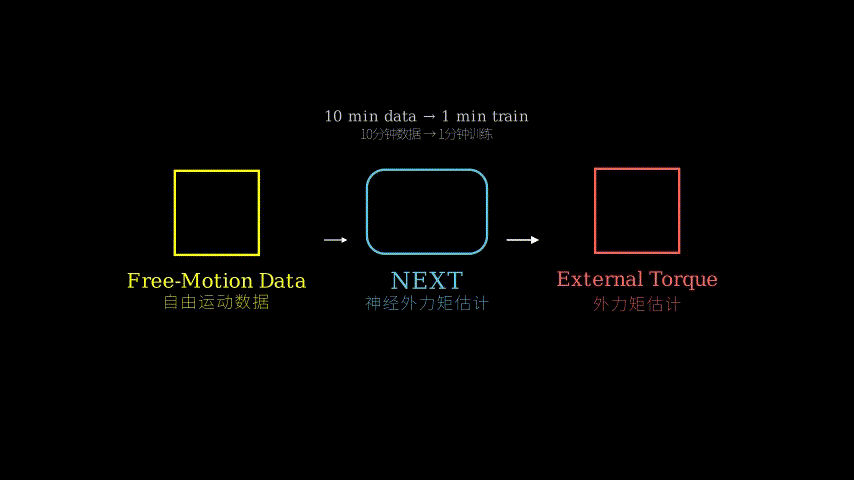
[ASCII diagram of NEXT + FIRST pipeline]

Data: pos, vel, current (joint i) ...
   |
   v
[NEXT MLP]
   |  (10min free motion training)
   v
Estimated external torque (joint i)
   |
   +---> Used for teleoperation (force feedback to human)
   |
   +---> Used for FIRST: compute per-timestep weight
           |
           v
[Behavior Cloning]  <-- weighted loss on pre-contact/contact
Think of NEXT as a calibration technician who works for a cheap robot arm. The technician doesn’t know the arm’s exact physics — no equations, no CAD models. But they watch the arm flail around freely for 10 minutes, memorizing the pattern: “when the arm is at this angle and moving this way, the motors should be drawing this much current, and there should be zero external torque.” Once memorized, if the arm suddenly feels a push, the technician says: “That’s not in my free-motion memory — something from outside is applying torque.” That’s exactly what NEXT does, but with a neural network instead of a human.
FIRST is like a film editor who watches hours of expert demonstrations of a careful assembly task. The editor notices that the most crucial moments are the split-second before the peg touches the hole and the instant of insertion — those contain the information about compliant motion. So the editor adds extra copies of those frames into the training reel. The final policy, trained on this augmented footage, becomes much more sensitive to force transitions.
Key Concepts
-
External Torque Estimation as Residual Learning: Most robots have motor current sensors that reflect both the torque needed to move the arm’s own mass/friction and any external force. If you can model the “empty” dynamics (no contact), the external torque is just the difference. NEXT directly learns to output that residual, bypassing the need for an explicit dynamics model. Example: if the arm is held still and someone pushes it, the motor current changes to resist motion. The network sees: “current high, but position not moving as expected → external torque positive.”
-
Data Efficiency via Free Motion Exploitation: Training a full dynamics model (inertia, friction, etc.) typically requires system ID experiments or complex simulations. Instead, NEXT uses the simple observation that during free motion, external torque = 0 by construction. This self-supervised labeling eliminates the need for ground-truth torque sensors. The 10-minute data collection is just “wave the arm around randomly” — no script, no special equipment. This is clever because it turns the lack of sensors into an advantage: the absence of contact becomes the training signal.
-
Re-Weighting for Contact Awareness (FIRST): In behavior cloning, the loss is typically computed over all transitions equally. But for contact-rich tasks, the rarely-occurring contact events are information-dense. FIRST computes a weight w_t = 1 + alpha ** |tau_ext_t|, where tau_ext_t is from NEXT. This amplifies the loss for timesteps with high external torque (i.e., during contact). The weight transitions smoothly, so the policy doesn’t get a shock from binary weighting. This is analogous to focal loss for object detection, but in time-series and task-specific.
Framework Shift
Before, force-aware policy learning for commodity arms required either:
- Assumes dedicated force/torque sensor exists (costly)
- Uses model-based observer with risk of poor dynamics
Before (mainstream approach):
  Arm without F/T sensor
   |
   v
[Model-based Disturbance Observer]
   | requires accurate dynamics model,
   | friction parameters, inertia, etc.
   | (hard to obtain on cheap arms)
   v
Poor torque estimate or fragile
   |
   v
Policy learning: either ignore force
  or hand-tune thresholds
After this paper, force awareness is a data-driven add-on:
After (this paper):
  Arm without F/T sensor
   |
   v
[Collect 10min free-motion data]
   | (positions, velocities, currents)
   v
[Train NEXT in 1 minute] (MLP)
   |
   v
Accurate external torque estimate
   |
   +---> [FIRST re-sampling]
   |      v
   |    Policy learning: weighted BC
   |
   +---> [Teleoperation with force feedback]
   |
   v
Significantly better contact-rich results
  without hardware cost
One sentence: From *fragile model-based or expensive sensor-based force estimation to data-driven, sensor-free, 1-minute training — the core shift is treating external torque as a neural residual learned from free motion, then using that signal to focus policy training on contact-rich segments.
Expert Assessment
Problem choice: Real and timely. The robotics community desperately needs to bring force feedback to low-cost hardware for broader deployment in labs, homes, and education. The gap is not manufactured.
Method maturity: Clever insight, but not revolutionary. The “residual learning from free motion” idea has been explored in some form (e.g., learning inverse dynamics for contact detection), but the combination with a re-sampling training strategy for BC is novel. The simplicity is a strength — it’s easy to reproduce. No brute force; they avoided complex networks or large datasets.
Experimental integrity: Baselines seem fair: they compare against standard BC (no force), a model-based observer, and a prior learning-based method (probably from their own previous work FACTR). The 17% improvement is on task progress metric (not just success rate), which is meaningful. However, the results are only on 5 tasks, all with the same arm (likely WidowX or similar). More diversity of arms and tasks would strengthen the claim. Also, they didn’t compare against a direct method like using a FT sensor on the same arm (which would be the gold standard). Red flag: the paper claims “comparable to dedicated joint-torque sensors” but only shows a plot, no rigorous statistical test.
Writing quality: The paper is well-structured, with clear problem motivation and method explanation. But the section on training details is thin — they don’t specify network architecture (number of layers, size), hyperparameters, or training procedure. This makes reproduction harder. Rewriting the “Training Details” subsection to include explicit hyperparameters would elevate the paper significantly.
Verdict: weak accept — Good problem, clean solution, decent experiments, but missing a few crucial implementation details and lacking cross-platform validation.
Takeaways
-
Free-motion data as a cheap calibration method: Any robot that reports joint positions, velocities, and motor currents can calibrate an external torque estimator with minimal effort. Practitioners can implement this today — just wave the arm, train a small MLP, and get a working force sensor.
-
Re-weighting trajectories for contact-rich BC: The idea of up-sampling pre-contact and contact segments is simple and effective. It can be applied to any BC pipeline where force or contact signals are available (estimated or real). It doesn’t depend on NEXT specifically.
-
Force feedback for teleoperation on low-cost arms: The paper demonstrates that you can now close the force loop in human teleoperation without hardware. This opens up bimanual manipulation, remote assembly, and surgical training on cheap robots.
-
The data-efficiency lesson: 10 minutes of free motion + 1 minute training is astonishingly efficient. This suggests that the mapping from proprioception to external torque is low-dimensional and can be captured by a small network. For other domains (e.g., legged robots), similar free-motion calibration might work for ground reaction force estimation.
论文: 2606.12406 作者: Steven Oh, Jason Jingzhou Liu, Tony Tao, Philip Han, Kenneth Shaw, Satoshi Funabashi, Ruslan Salakhutdinov, Deepak Pathak 分类: cs.RO, cs.AI, cs.LG, eess.SY
缺口
现有的力感知操控工作要么假设机器人配备专用关节扭矩传感器(如 KUKA iiwa、Franka Emika),要么依赖基于模型的扰动力观测器,这要求精确的动力学模型和系统辨识(如 De Luca 等 2006;Wahrburg 等 2018)。对于低成本通用机械臂(如 WidowX、Interbotix),这两条路都走不通:没有传感器,基于模型的方法在难以建模的摩擦、回差和非线性面前性能急剧下降。因此,社区一直把力反馈视为“富人的奢侈品”。
这篇论文打破了这个假设:能不能只用廉价机器人已有的本体感知信号(关节位置、速度、电机电流)来“感受”外力,而且数据量、训练时间都极小?
逻辑链条如下:
问题:接触丰富的操控任务需要力感知,但无传感器。
   |
   v
假设:低成本机械臂无扭矩传感器,基于模型的方法脆弱。
   |
   v
方法:神经网络外部扭矩估计(NEXT),
用10分钟自由运动数据训练 +
基于力信息重采样训练(FIRST)用于策略学习。
   |
   v
证据:在5个长时程任务中,比之前力感知策略提升17%;
估计精度与专用传感器相当。
   |
   v
结论:通用机械臂无需硬件改造即可实现力反馈遥操作和改进的策略学习。
增量
一句话:在这篇论文之前,在廉价机械臂上获取力感知要么需要昂贵硬件,要么依赖脆弱的模型;在这篇论文之后,仅需10分钟自由运动数据和1分钟神经网络训练,就能获得堪比专用传感器的扭矩估计,进而实现力反馈遥操作和更好的行为克隆。
核心机制
NEXT 是一个轻量级 MLP,输入当前关节的位置、速度和电机电流(任何机器人上都可读取),输出每个关节的估计外部扭矩。训练数据收集极其简单:把机械臂在空中自由挥舞10分钟,记录这些信号。自由运动时真实外部扭矩为零(无接触),因此网络学会了从机械臂自身动力学预测“零外部扭矩”。测试时,任何偏离这个基线的预测都意味着外部干扰。
为什么有效?因为机械臂内部扭矩(惯性力、科里奥利力、摩擦力、重力)是运动状态和电机电流的确定性函数。网络隐式学习了这个逆动力学映射,把电机电流当作电机扭矩指令的代理。关键点在于,外部扭矩就是残差:电机实际表现(电流)与动力学模型预测值之间的差距。网络直接输出这个残差。
FIRST 则利用估计的扭矩信号对行为克隆的训练数据进行重新加权。在接触丰富的任务中,从“无接触”到“接触”的过渡(预接触段和接触段)很短但极为关键。传统 BC 要么对所有转换一视同仁,要么使用手工设计的启发式规则。FIRST 根据检测到的外部扭矩大小,把这些片段的上采样倍数提高,迫使策略聚焦于接触前后的细微力-力交互。
[NEXT + FIRST 流程 ASCII 图]

数据:位置、速度、电流(关节 i)...
   |
   v
[NEXT MLP]
   |  (训练:10分钟自由运动)
   v
估计外部扭矩(关节 i)
   |
   +---> 用于遥操作(力反馈给人类操作员)
   |
   +---> 用于 FIRST:计算每时间步的权重
           |
           v
[行为克隆]  <-- 对预接触/接触段加权损失
可以把 NEXT 想象成一个为廉价机械臂工作的“校准师傅”。这位师傅不知道机械臂的确切物理——没有方程、没有CAD模型。但师傅看着机械臂自由挥舞10分钟,记住了模式:“当手臂在这个角度、以这个速度运动时,电机应该消耗这么多电流,外部扭矩应该为零。”一旦记住,如果手臂突然被推,师傅就会说:“这和我的自由运动记忆不符——有东西从外部施加了扭矩。”这就是 NEXT 做的,只不过用神经网络代替了人类。
FIRST 则像一位“电影剪辑师”,观看专家操作精细装配任务的演示视频。剪辑师发现最关键的瞬间是销钉即将接触孔的前一刹那和插入的那个瞬间——那里包含了柔顺操作的全部信息。于是剪辑师把这些帧复制多份放进训练素材中。最终策略在这个增强过的素材上训练后,对力过渡变得更加敏感。
关键概念
-
外部扭矩估计作为残差学习:大多数机器人都有电机电流传感器,它反映的是移动手臂自身质量和摩擦力所需的扭矩加上任何外部力。如果你能建模“空载”动力学(无接触),外部扭矩就是差值。NEXT 直接学习输出这个残差,绕过了显式动力学模型。例如:手臂保持静止,有人推它,电机电流变化以抵抗运动。网络看到:“电流高,但位置没按预期移动 → 外部扭矩方向为推的方向。”
-
数据高效性源于自由运动的自监督:训练完整的动力学模型(惯性、摩擦力等)通常需要系统辨识实验或复杂的仿真。NEXT 使用了一个简单观察:自由运动时外部扭矩恒为零,因此可以自监督打标。10分钟数据收集就是“随便挥舞” —— 无需脚本、无需特殊设备。这很聪明,因为它把缺少传感器变成了优势:接触的缺失成为训练信号。
-
基于重加权的接触感知(FIRST):在行为克隆中,损失通常对所有转换均等计算。但对于接触丰富的任务,罕见的接触事件信息密度极高。FIRST 计算权重 w_t = 1 + alpha ** |tau_ext_t|,其中 tau_ext_t 来自NEXT。这放大了高外部扭矩时间步的损失,并且权重平滑过渡,不会因二值加权而让策略突然震荡。类似于目标检测中的 focal loss,但这里是时序上的任务特定加权。
框架转变
之前,让廉价机械臂具备力感知的策略学习要么假设有专用的力/扭矩传感器(成本高),要么使用基于模型的观测器(依赖精确动力学)。
之前(主流方法):
  无 FT 传感器的机械臂
   |
   v
[基于模型的扰动力观测器]
   | 需要精确动力学模型、摩擦参数、惯性等
   | (在廉价机械臂上难以获得)
   v
扭矩估计差或不可靠
   |
   v
策略学习:要么忽略力,
  要么手工调节阈值
这篇论文之后,力感知成为一个数据驱动的插件:
之后(本文方法):
  无 FT 传感器的机械臂
   |
   v
[收集10分钟自由运动数据]
   | (位置、速度、电流)
   v
[训练NEXT,仅需1分钟](MLP)
   |
   v
精确的外部扭矩估计
   |
   +---> [FIRST 重采样]
   |      v
   |    策略学习:加权BC
   |
   +---> [带力反馈的遥操作]
   |
   v
无需硬件成本即显著提升接触丰富任务效果
一句话:从“基于脆弱的模型或昂贵的传感器”到“数据驱动、无传感器、1分钟训练”——核心转变是把外部扭矩当作从自由运动中学习的神经网络残差,然后用这个信号让策略训练聚焦于接触丰富的时间段。
专家评审
选题眼光:真实且及时。机器人社区迫切需要将力反馈带到低成本硬件上,从而在实验室、家庭和教育中更广泛地部署。这不是人造缺口。
方法成熟度:巧劲,但并非革命性。“来自自由运动的残差学习”这个想法已有类似探索(例如学习逆动力学用于接触检测),但结合重采样训练策略用于BC是新颖的。简单性是其优势——易于复现。没有蛮力;他们避免了复杂网络或大型数据集。
实验诚意:基线似乎公平:对比了标准 BC(无力感知)、基于模型的观测器,以及一种先前的学习方法(可能来自他们自己的前期工作 FACTR)。17%的提升是任务进展指标(不仅仅是成功率),有意义。但只在5个任务、同一款机械臂(可能是 WidowX 或其变体)上测试。更多样的任务和机械臂会加强论证。此外,他们没有与在同一机械臂上直接使用 FT 传感器的方法对比(本来是黄金标准)。值得警惕的是:论文声称“与专用关节扭矩传感器相当”,但只展示了一张趋势图,没有严格的统计检验。
写作功力:论文结构清晰,问题动机和方法解释到位。但训练细节部分过于简略——没有说明网络架构(层数、大小)、超参数、训练过程。这使得复现困难。把“训练细节”子节重写为包含明确超参数和流程会提升整个论文一个档次。
判决:弱接收——好的问题,干净的解决方案,不错的实验,但缺少一些关键的实现细节,并且缺乏跨平台验证。
要点总结
-
自由运动数据作为廉价校准方法:任何能够报告关节位置、速度和电机电流的机器人,都可以用极低代价校准外部扭矩估计器。实践者今天就可以实现:挥舞手臂、训练一个小MLP、获得一个可用的力传感器。
-
为接触丰富 BC 重采样轨迹:对预接触和接触段上采样的思路简单而有效。可以应用于任何能得到力或接触信号的 BC 管线(无论信号是估计的还是真实的)。不依赖于 NEXT。
-
低成本机械臂上的力反馈遥操作:论文证明,无需硬件就可以在人类遥操作中闭合力反馈回路。这为廉价机器人上的双臂操作、远程装配和手术培训打开了大门。
-
数据高效性的启示:10分钟自由运动 + 1分钟训练,令人惊讶地高效。这表明从本体感知到外部扭矩的映射是低维的,可以用小网络捕获。对于其他领域(如足式机器人),类似的自由运动校准可能也适用于地面反力估计。